
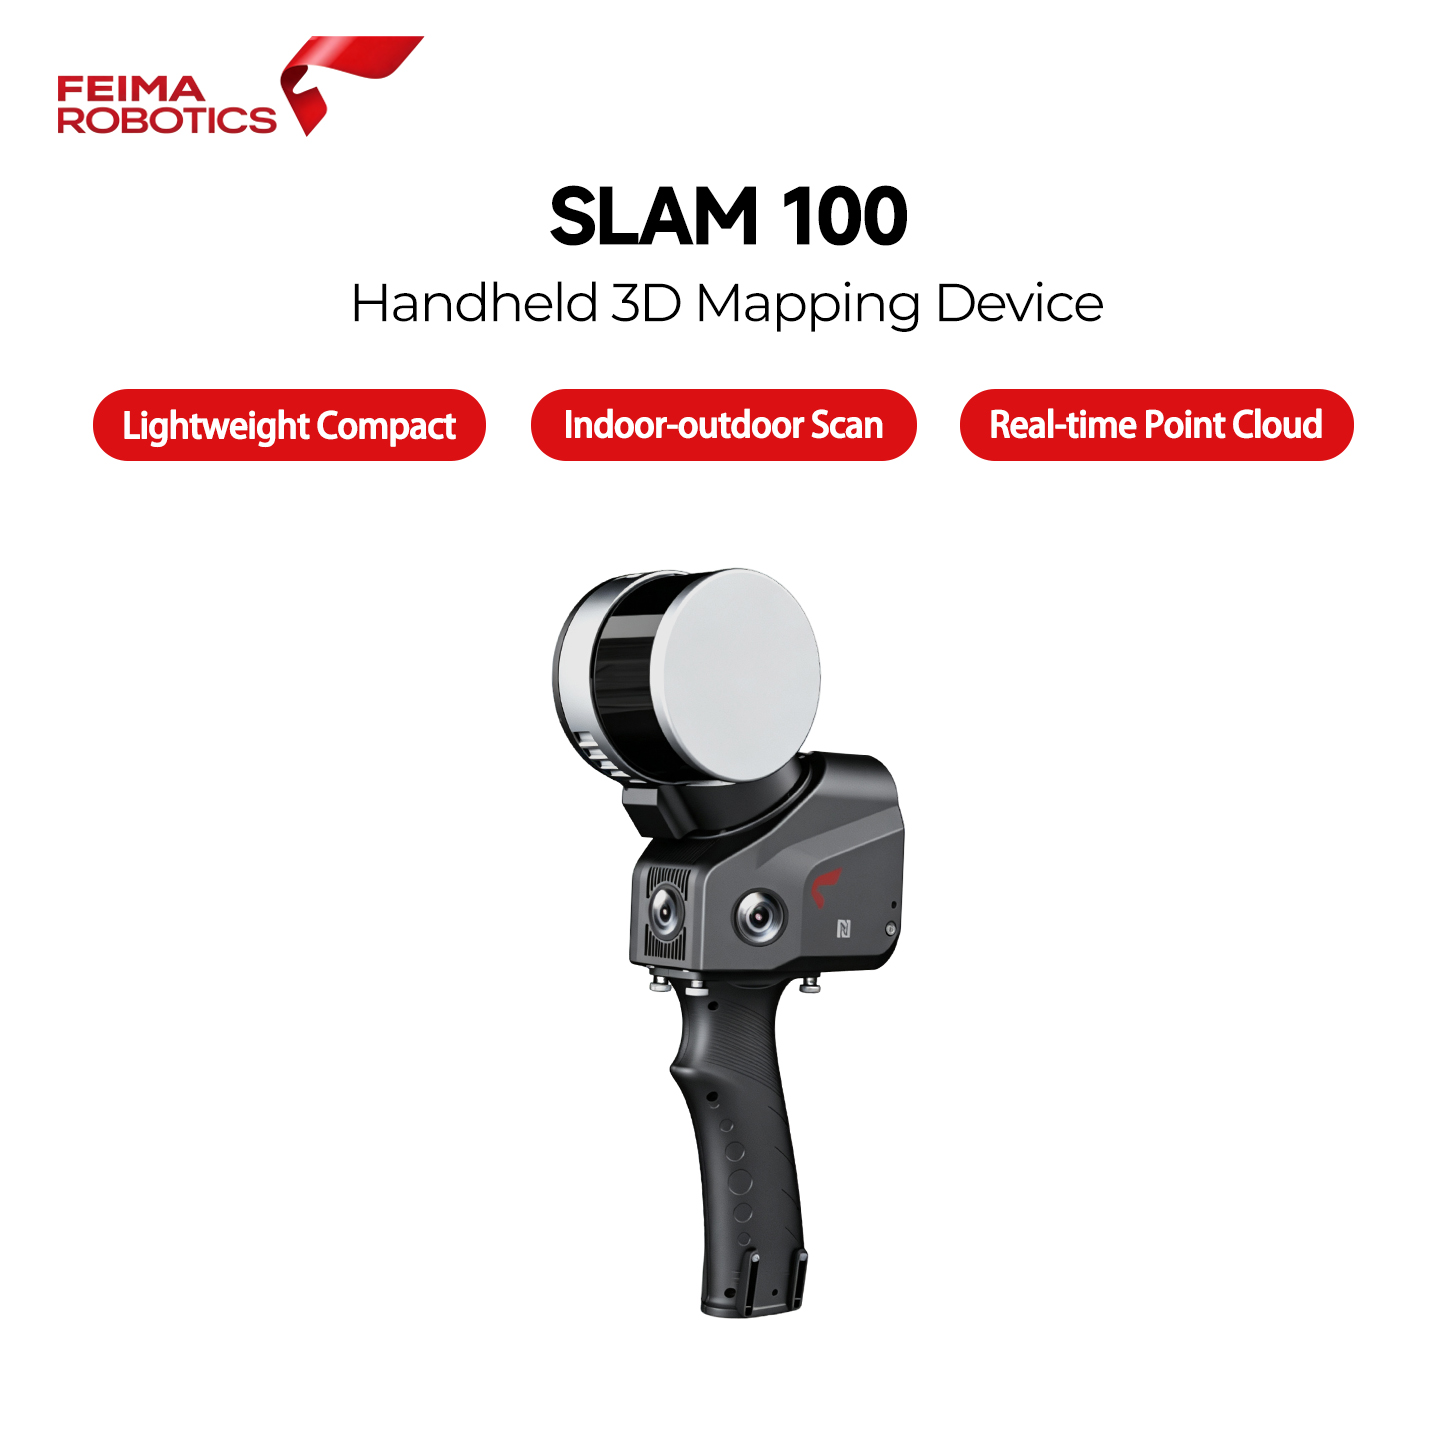
Feima SLAM100 Handheld SLAM LiDAR Scanner, Versatile Indoor & Outdoor 3D Mapping System
Core Advantages of SLAM100
Ultra-light Compact Design
Lightweight body, long-time handheld operation without fatigue, easy to transport to narrow indoor sites.
120m Effective Measuring Range
Suitable for indoor space, low-rise buildings, underground parking and small-scale outdoor scene scanning.
Built-in High Precision IMU
Stable SLAM mapping without GNSS signal, adapt to tunnels, workshops and all indoor closed environments.
Dual Panoramic Cameras
Real-time point cloud colorization, generate true-color measurable point cloud data efficiently.
Real-time On-site Reconstruction
Preview scanning results on mobile terminal immediately, avoid missing data in field operation.
High Cost Performance
Entry-level mobile LiDAR, lower investment, ideal choice for engineering teams focusing on indoor survey.
Reliable Precision for Indoor Mapping
Optimized indoor SLAM algorithm, effectively reduce cumulative error, deliver stable point cloud effect for interior reconstruction.
- Max Measuring Distance: 120 m
- Point Frequency: Up to 320,000 points per second
- High relative precision for indoor spatial measurement
- Support loop closure optimization to improve mapping stability
- Export LAS, LAZ, PLY point cloud for BIM and reconstruction
-
PRODUCT DESCRIPTION
-
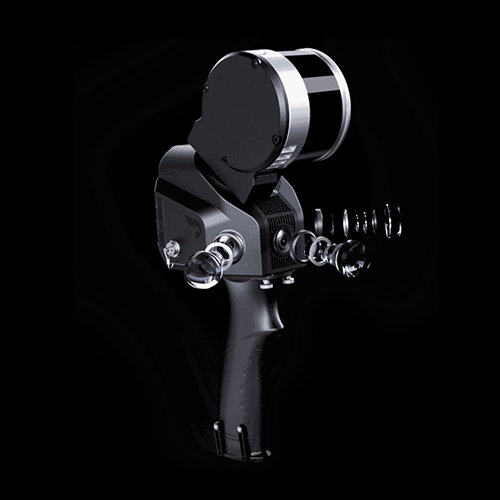
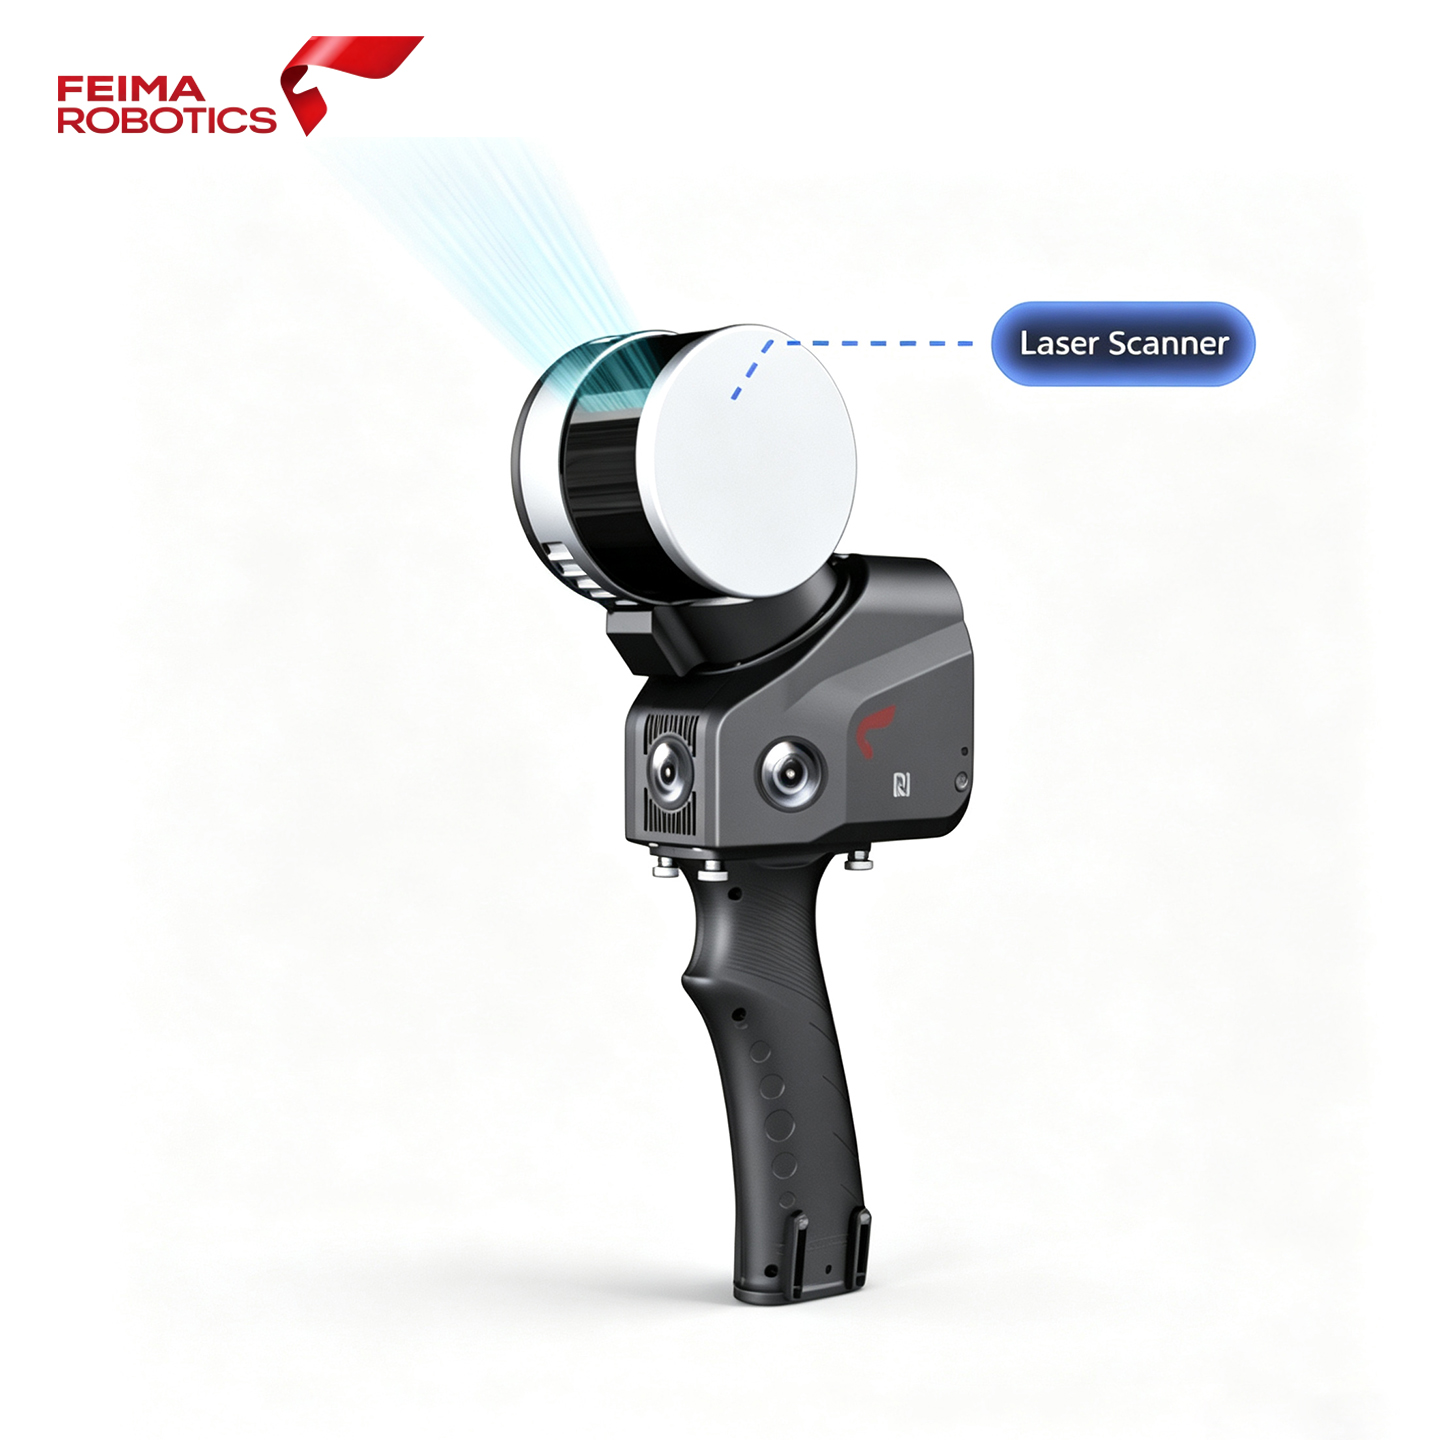
The Visible Light Cameras
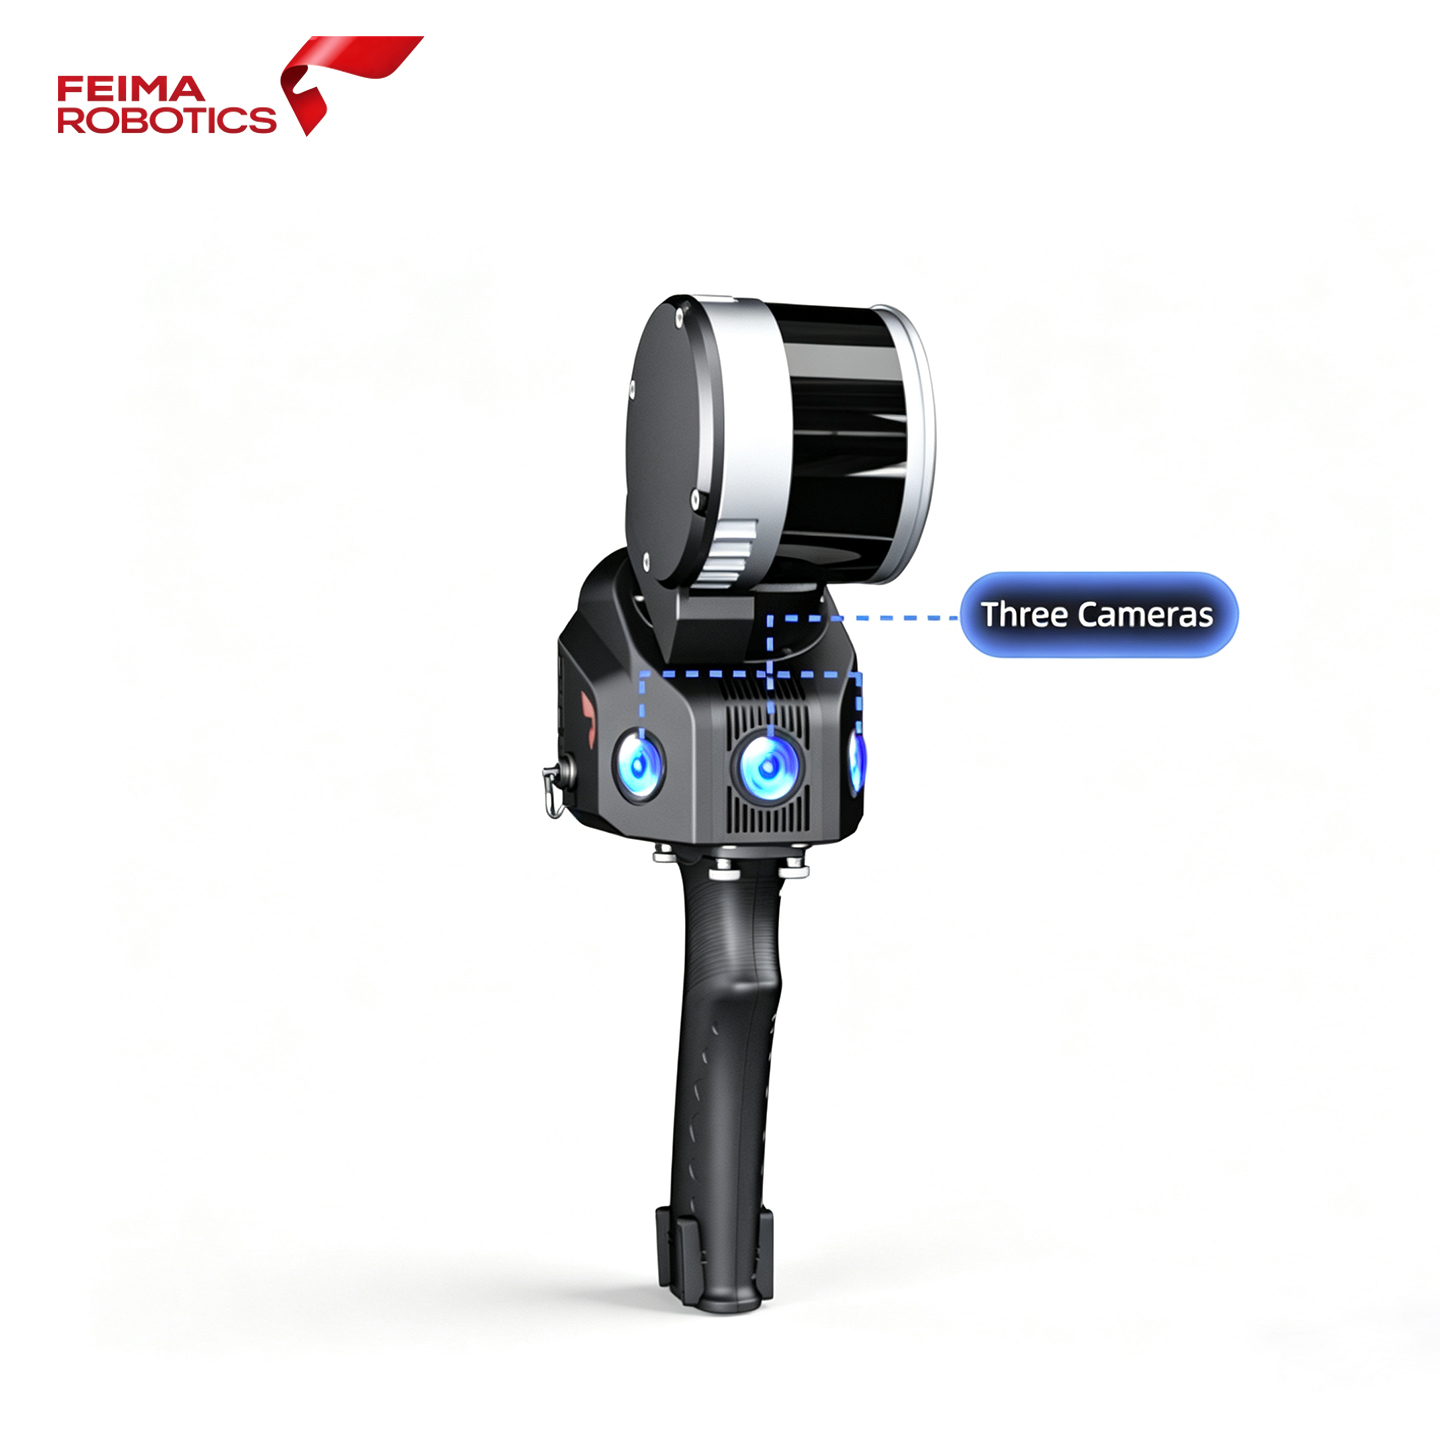
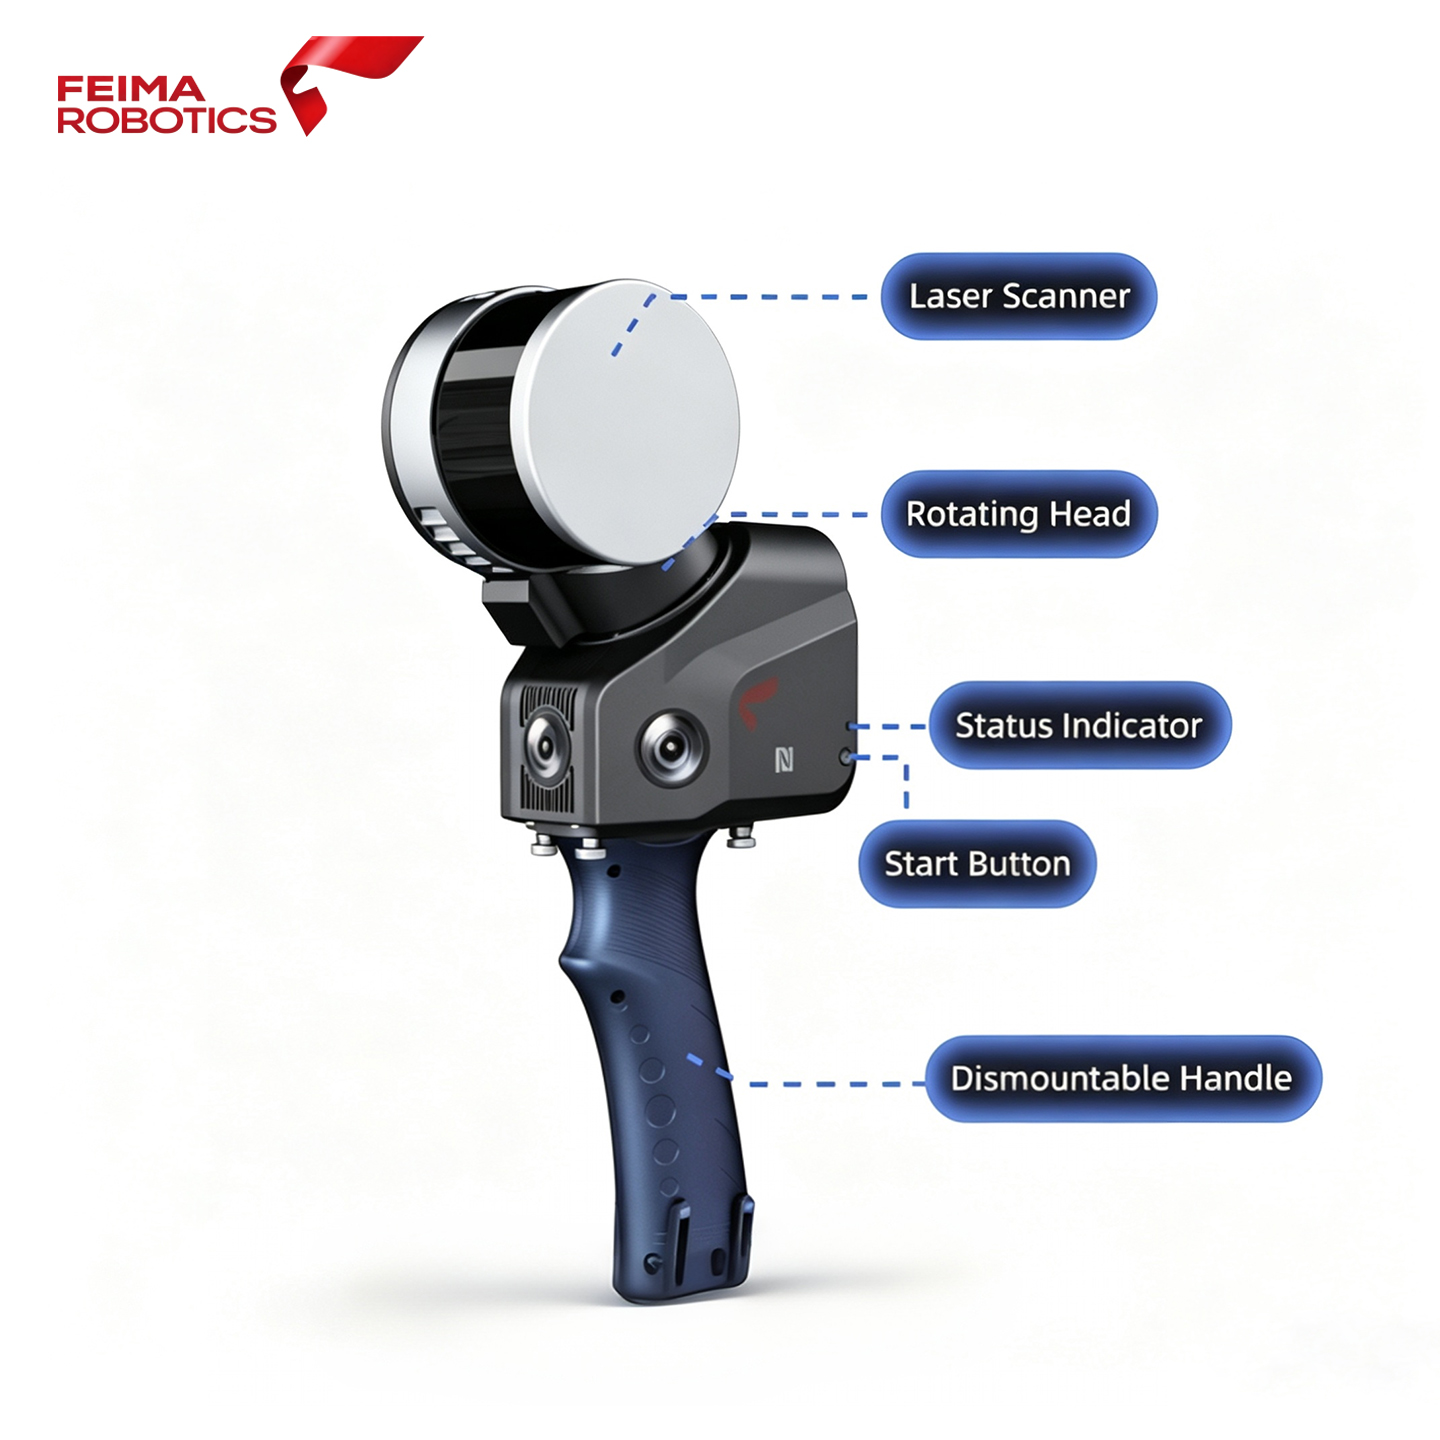
Three 5-megapixel cameras are adopted to form a horizontal 200-degree field of view and a vertical 100-degree field of view, which can synchronously obtain texture information and to furthermore produce color point clouds and partial panoramic images.
-
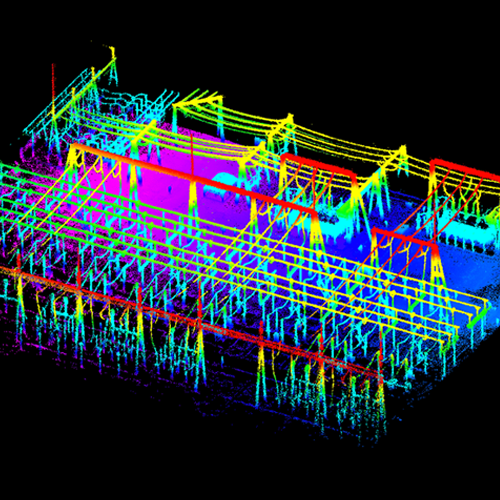
All-Scene Stable Scanning
The integrated high-precision positioning system supports reliable scanning with or without GNSS signals. It ensures steady continuous data collection in underground spaces, factory workshops and other complex indoor and outdoor environments.
-
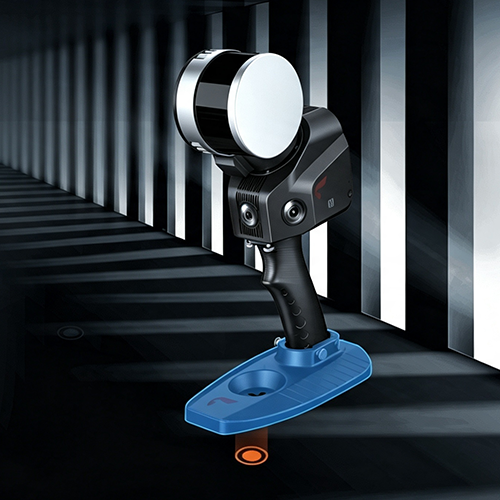
Automatic Point Capture
Without the need to manually add control points, SLAM100 can actively collect and automatically extract the control points and thus easily georeference the result data in the global coordinate system.
-
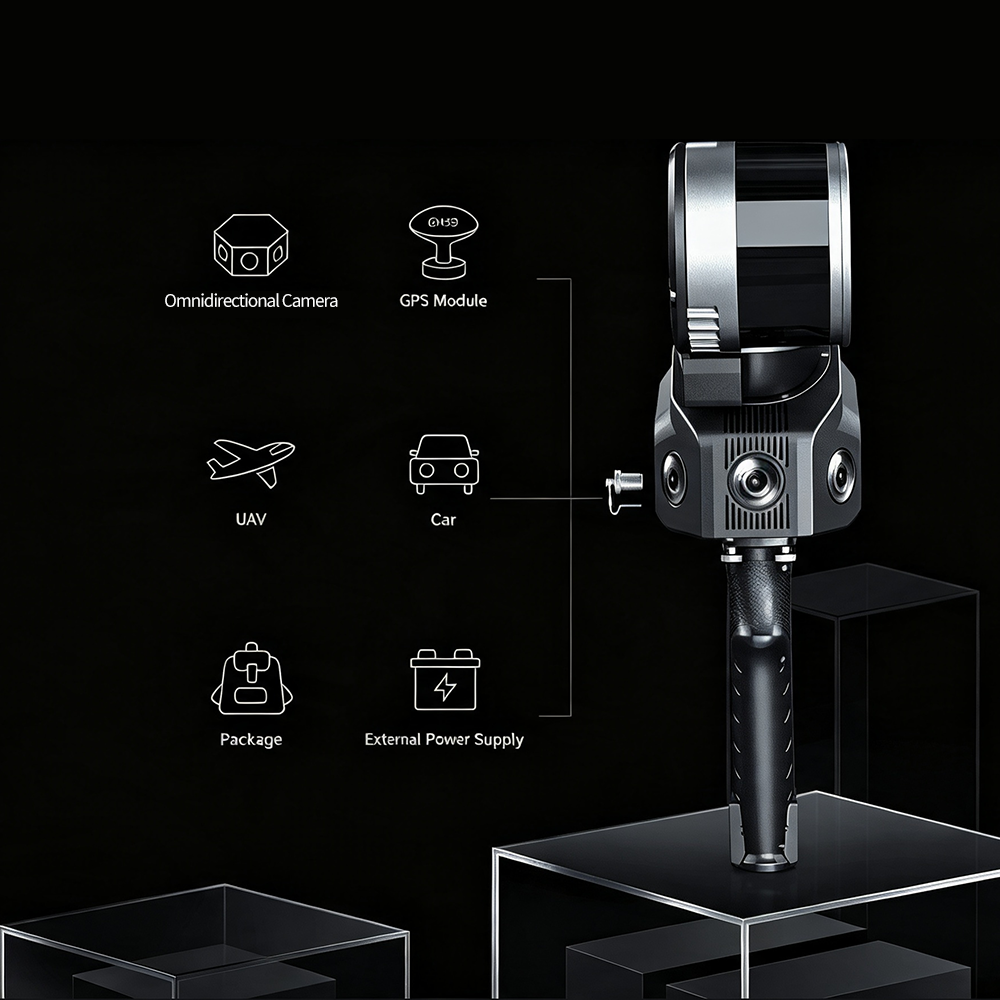
Rich External Interfaces
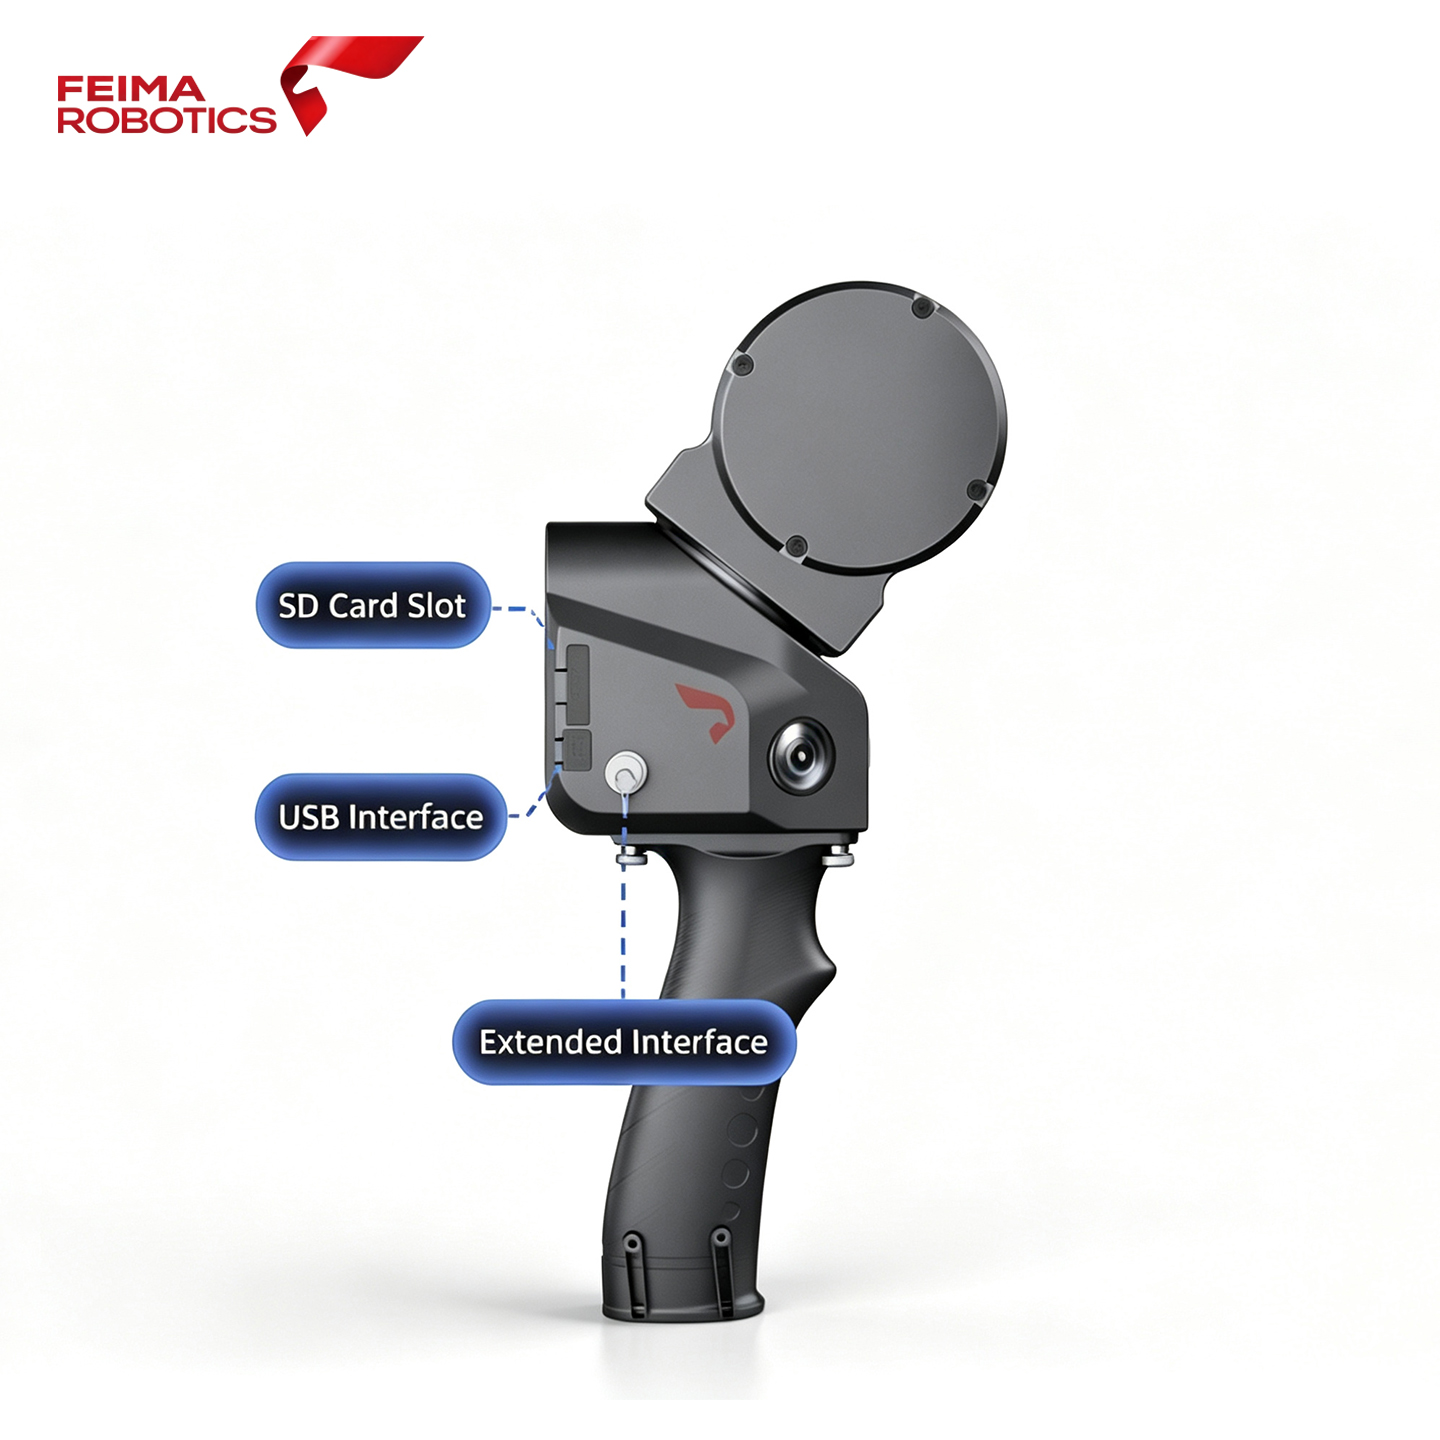
SLAM100 has a wealth of external interfaces, which can be connected to a panoramic camera, a GPS module, a car, a UAV and so on, to diversify data collections and adapt to more application scenarios.
Technical Specifications
| Item | Parameter |
|---|---|
| Laser Channel | 16 Lines |
| Max Measuring Range | 120 m |
| Point Cloud Rate | Up to 320,000 pts/sec |
| Panoramic Camera | Dual 8MP Fisheye Camera |
| GNSS Module | Not Built-in |
| Inertial System | Built-in High-precision IMU |
| Working Mode | Handheld / Backpack |
| Scanner Weight | Lightweight Compact Body |
| Single Battery Duration | ≥70 min |
| Support Software | SLAM GO APP, SLAM GO POST Pro |
Supporting Software
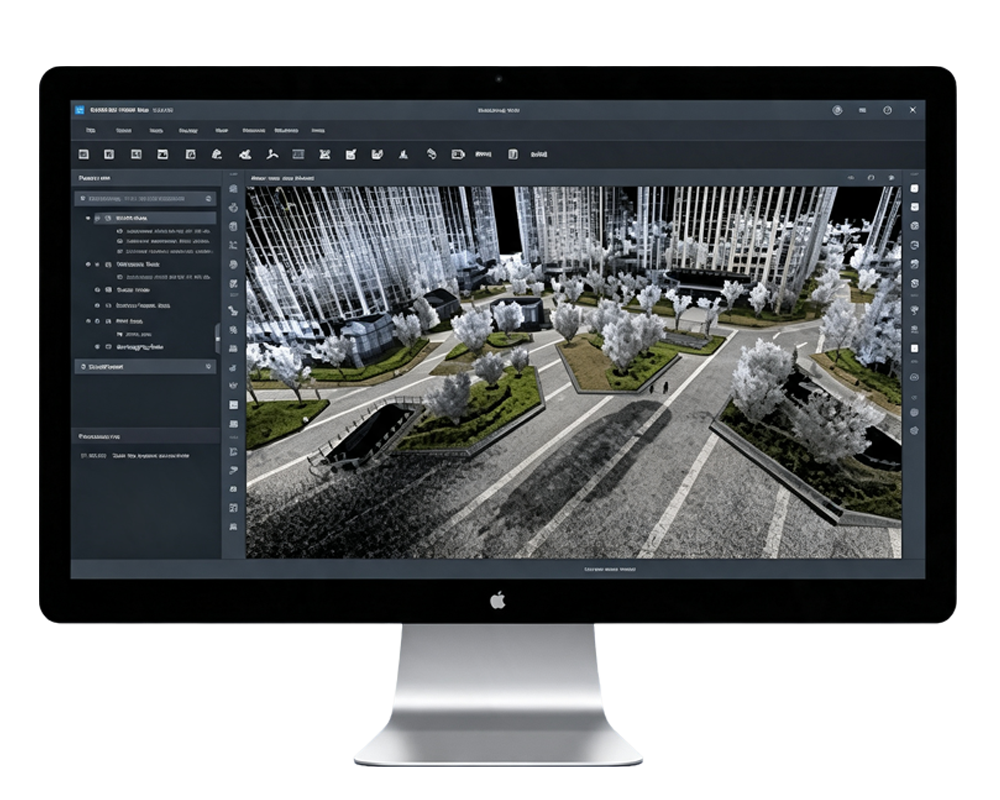
SLAM GO POST Pro is a professional PC-end data processing software specifically designed for Pocket3D. It is equipped with its own core data processing algorithm and supports the one-click generation ofpoint cloud, panoramic images, and Gaussian model results. It integrates a ful-process tool for resultbrowsing, visualization display, precise measurement, and interest point annotation. At the same time, itcan complete the unified management, batch processing, and fusion combination of multiple measure-ment data, and complete the post-processing of 3D data in one step.
High-Fidelity 3DGS Model Construction
Without relying on the SFM algorithm, it accurately recovers the pose of panoramic images in complex environments and generates high-quality Gaussian model data.
High-Precision Point Cloud Map Construction
Supporting the generation of indoor and outdoor colored point clouds with a relative accuracy of up to 2 cm.
High-Resolution Panoramic Image Stitching
Supporting the processing of original panoramic camera data, stitching high-resolution panoramic images with pose information, and achieving precise matching between panoramic images and point clouds.
Compatibility with Third-Party Modeling Software
It can output each frame of panoramic camera images and calibrated pose elements. It can also output standard Colmap-format data processed by the built-in SFM algorithm, compatible with mainstream or self-developed third-party modeling software such as MipMap and Postshot.
Result Browsing
Supporting the browsing and editing of point cloud data and 3DGS data results.
Note: Colored point clouds, panoramic images, and 3DGS models require an optional external camera.
Wide Range of Industry Applications
SLAM100
Handheld Laser Scanner — Technical Specifications
Overall Parameters
| Parameter | Specification |
|---|---|
| Laser Scanning FOV | 270° × 360° |
| Camera FOV | 200° (H) × 100° (V) |
| Relative Accuracy | 2 cm |
| Absolute Accuracy | 5 cm |
| Storage | 32 GB (Standard) |
| Power Supply | Replaceable battery / External power supply |
| External Power Supply Voltage | 20 V ~ 30 V |
| Internal Battery | 3350 mAh × 4 |
| Internal Battery Life | 2.5 h |
| Power Consumption | 25 W |
| Operating Temperature | -10 ℃ ~ 45 ℃ |
| Working Humidity | < 85% RH |
| Weight | 1588 g (Without battery) |
| Size | 372 mm × 163 mm × 106 mm (Without base) |
Sensor Parameters
| Parameter | Specification |
|---|---|
| Laser Class | Class 1 |
| Laser Channels | 16 |
| Maximum Ranging | 120 m |
| Laser Pulse Repetition Rate | 320 kpts/s |
| Echo Signal Intensity | 8 bits |
| Number of Cameras | 3 |
| Camera Resolution | 5 MP |
| NFC | Supported |