
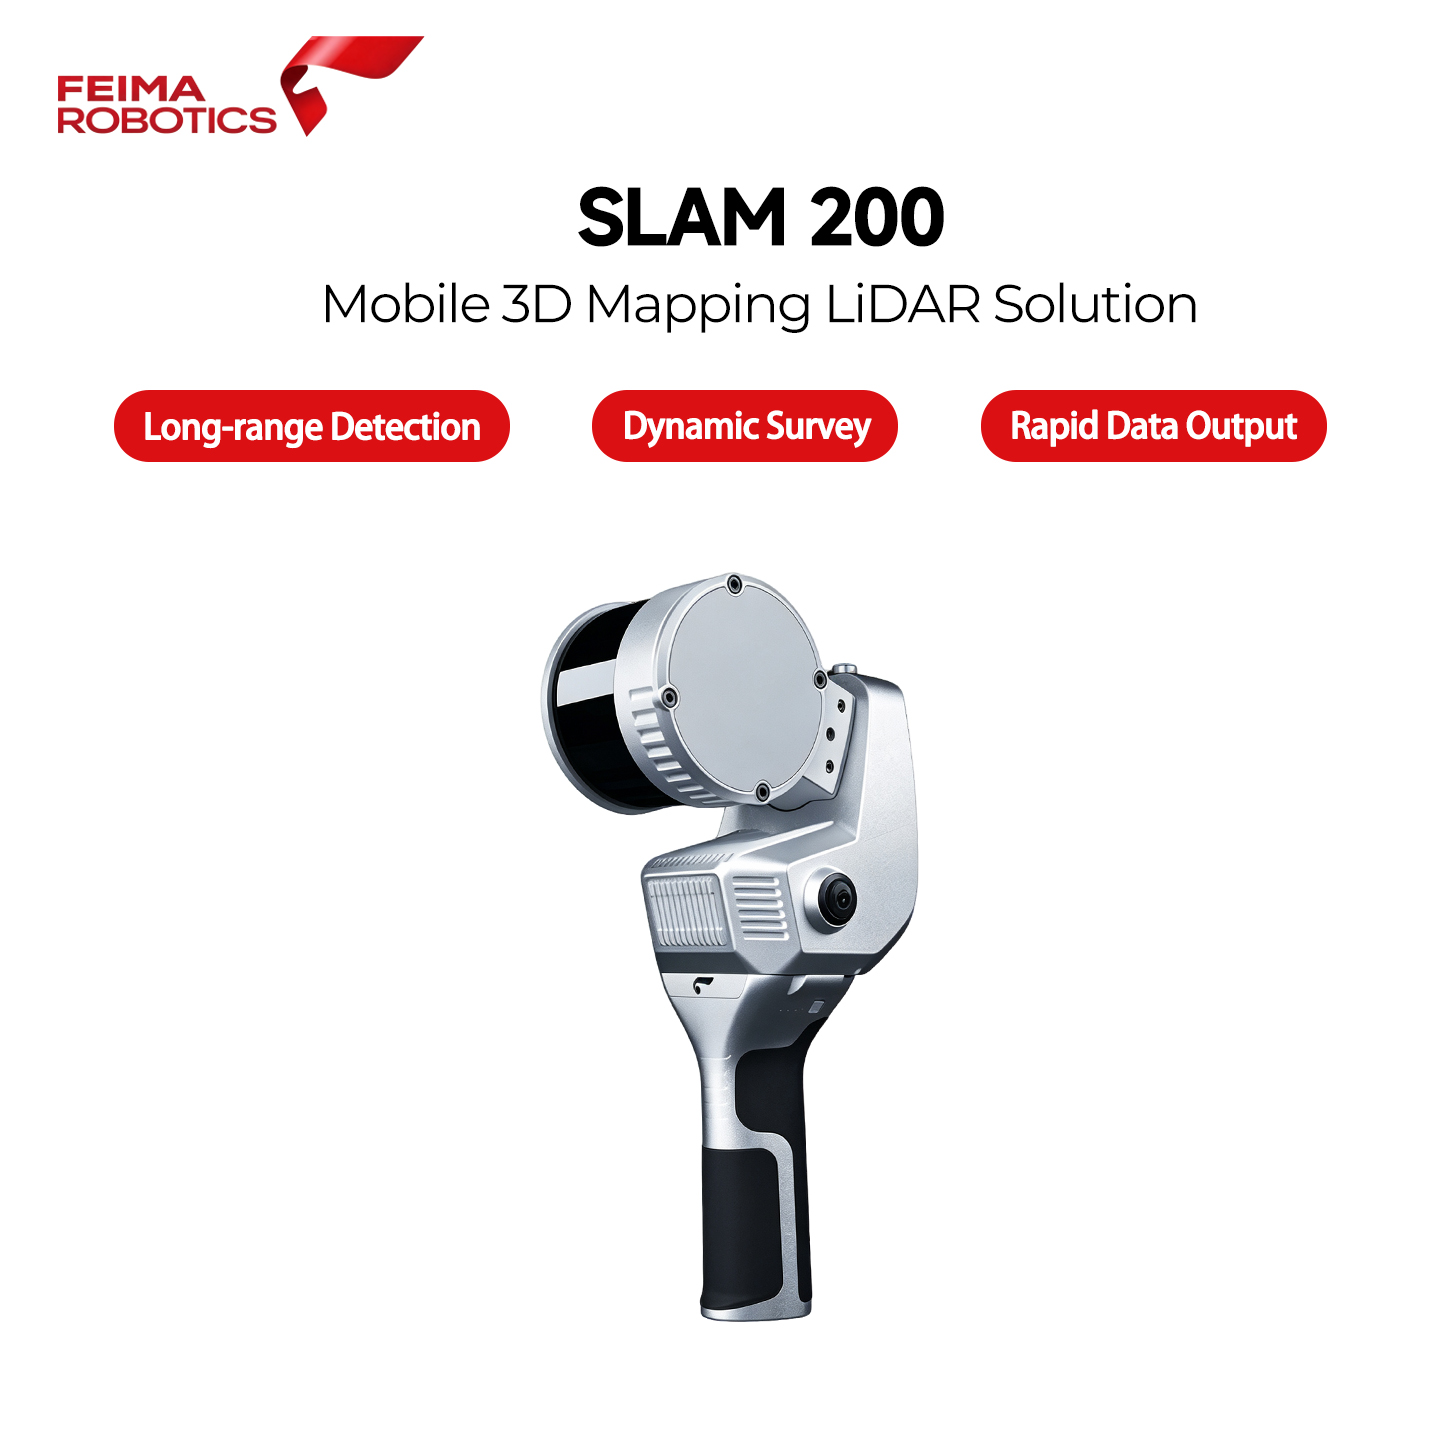
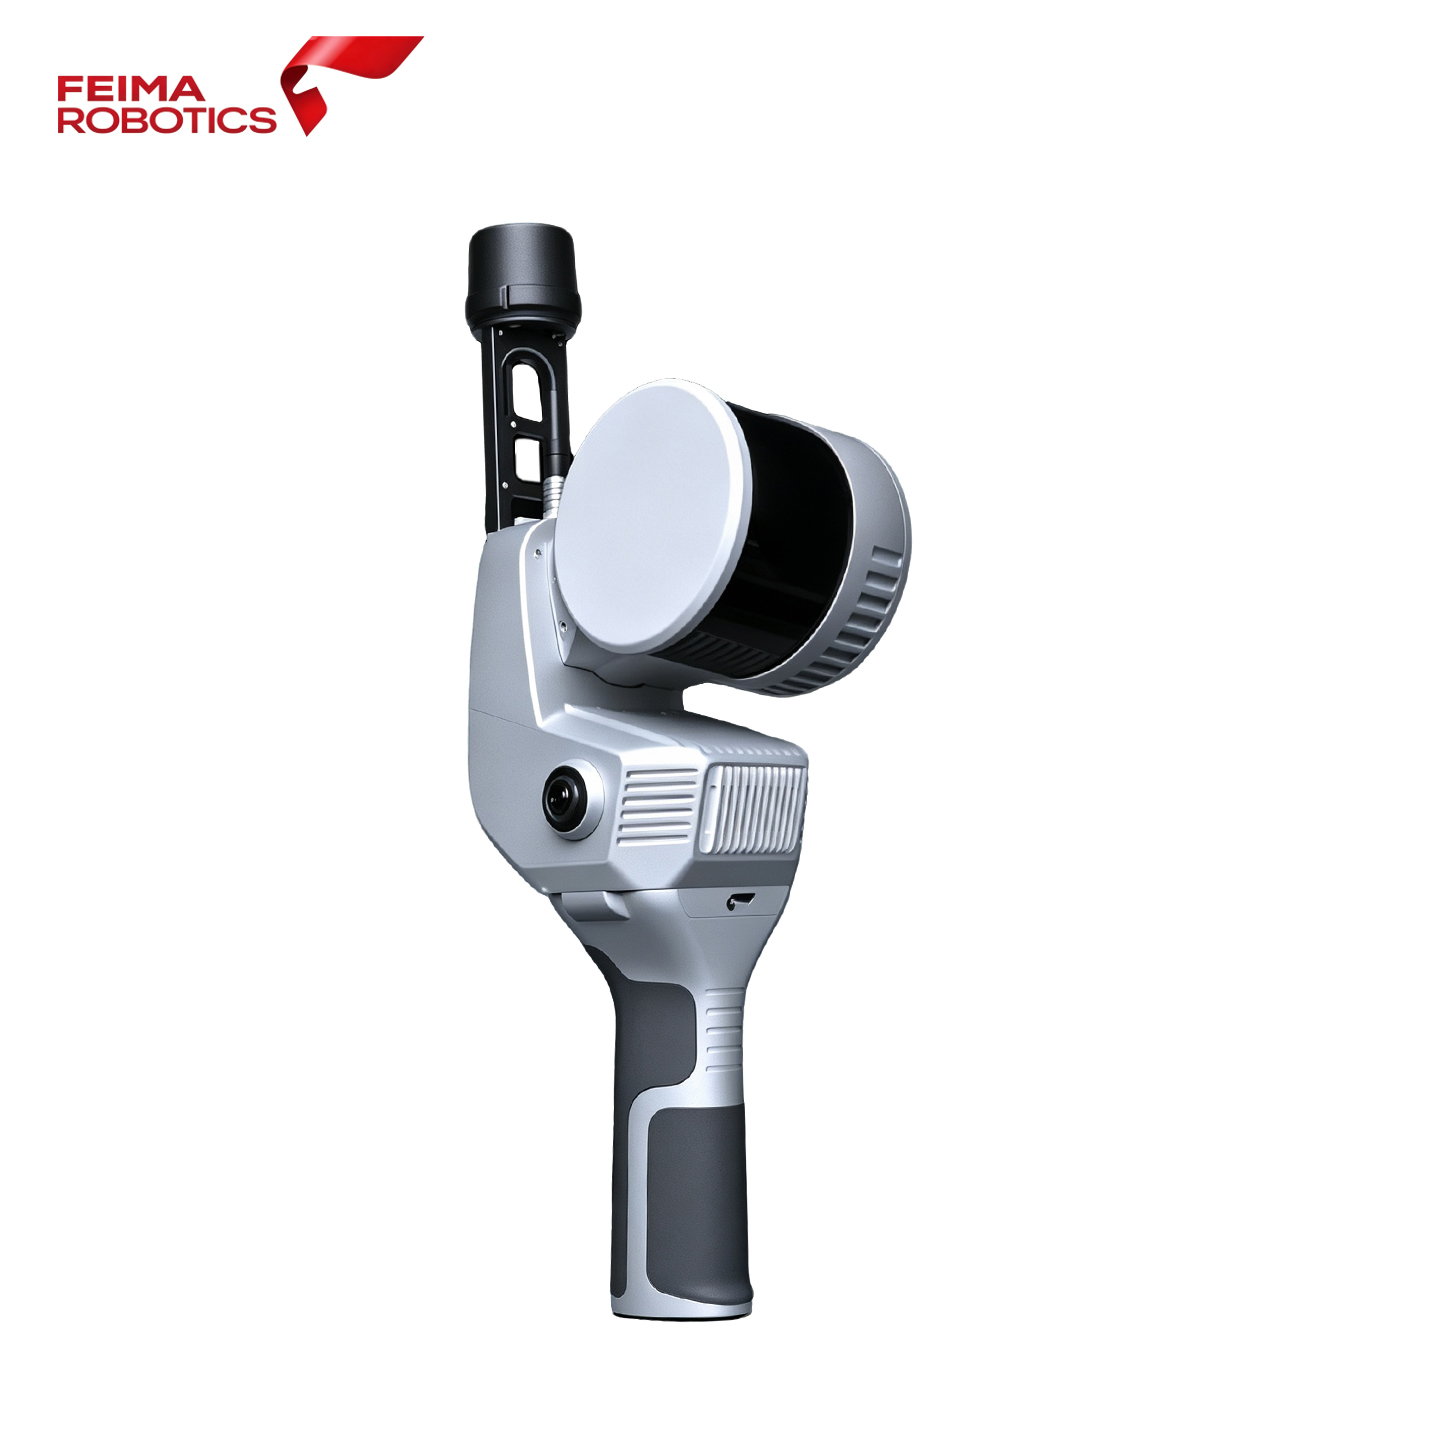
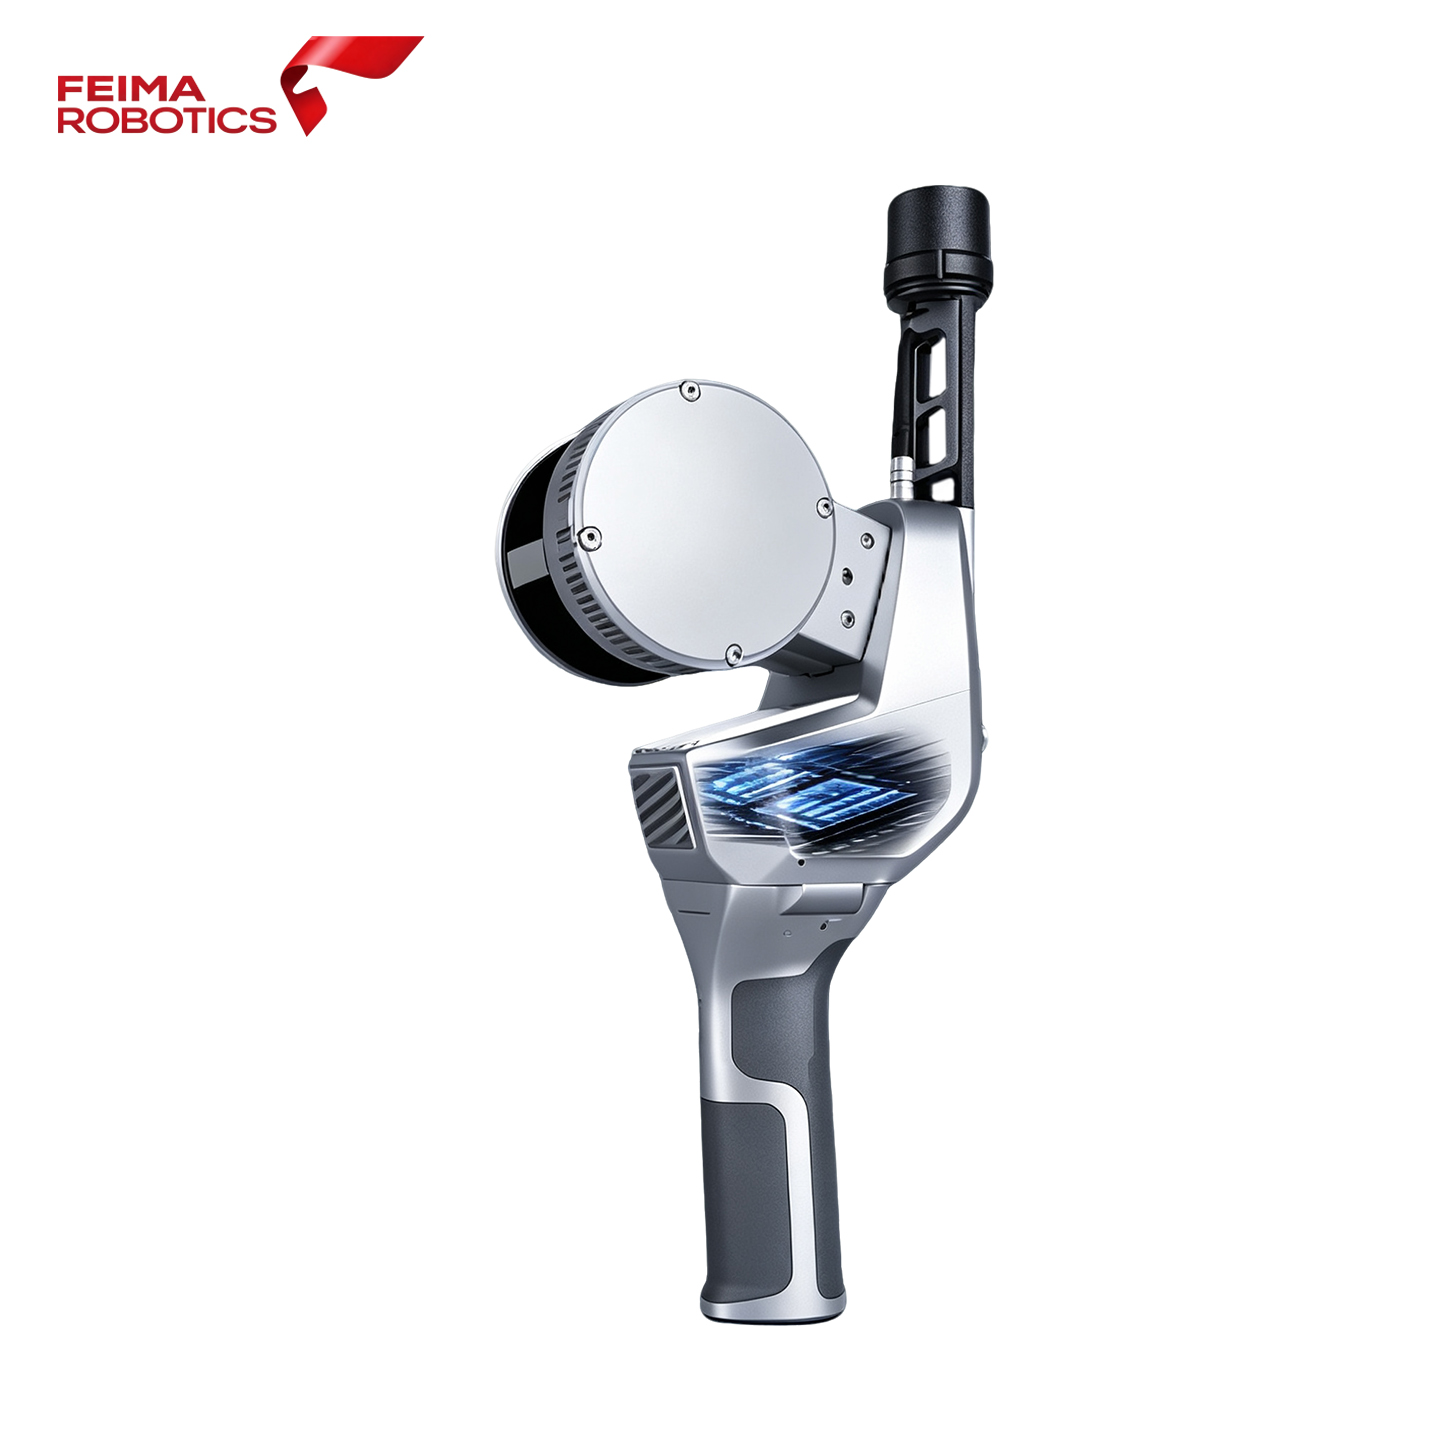
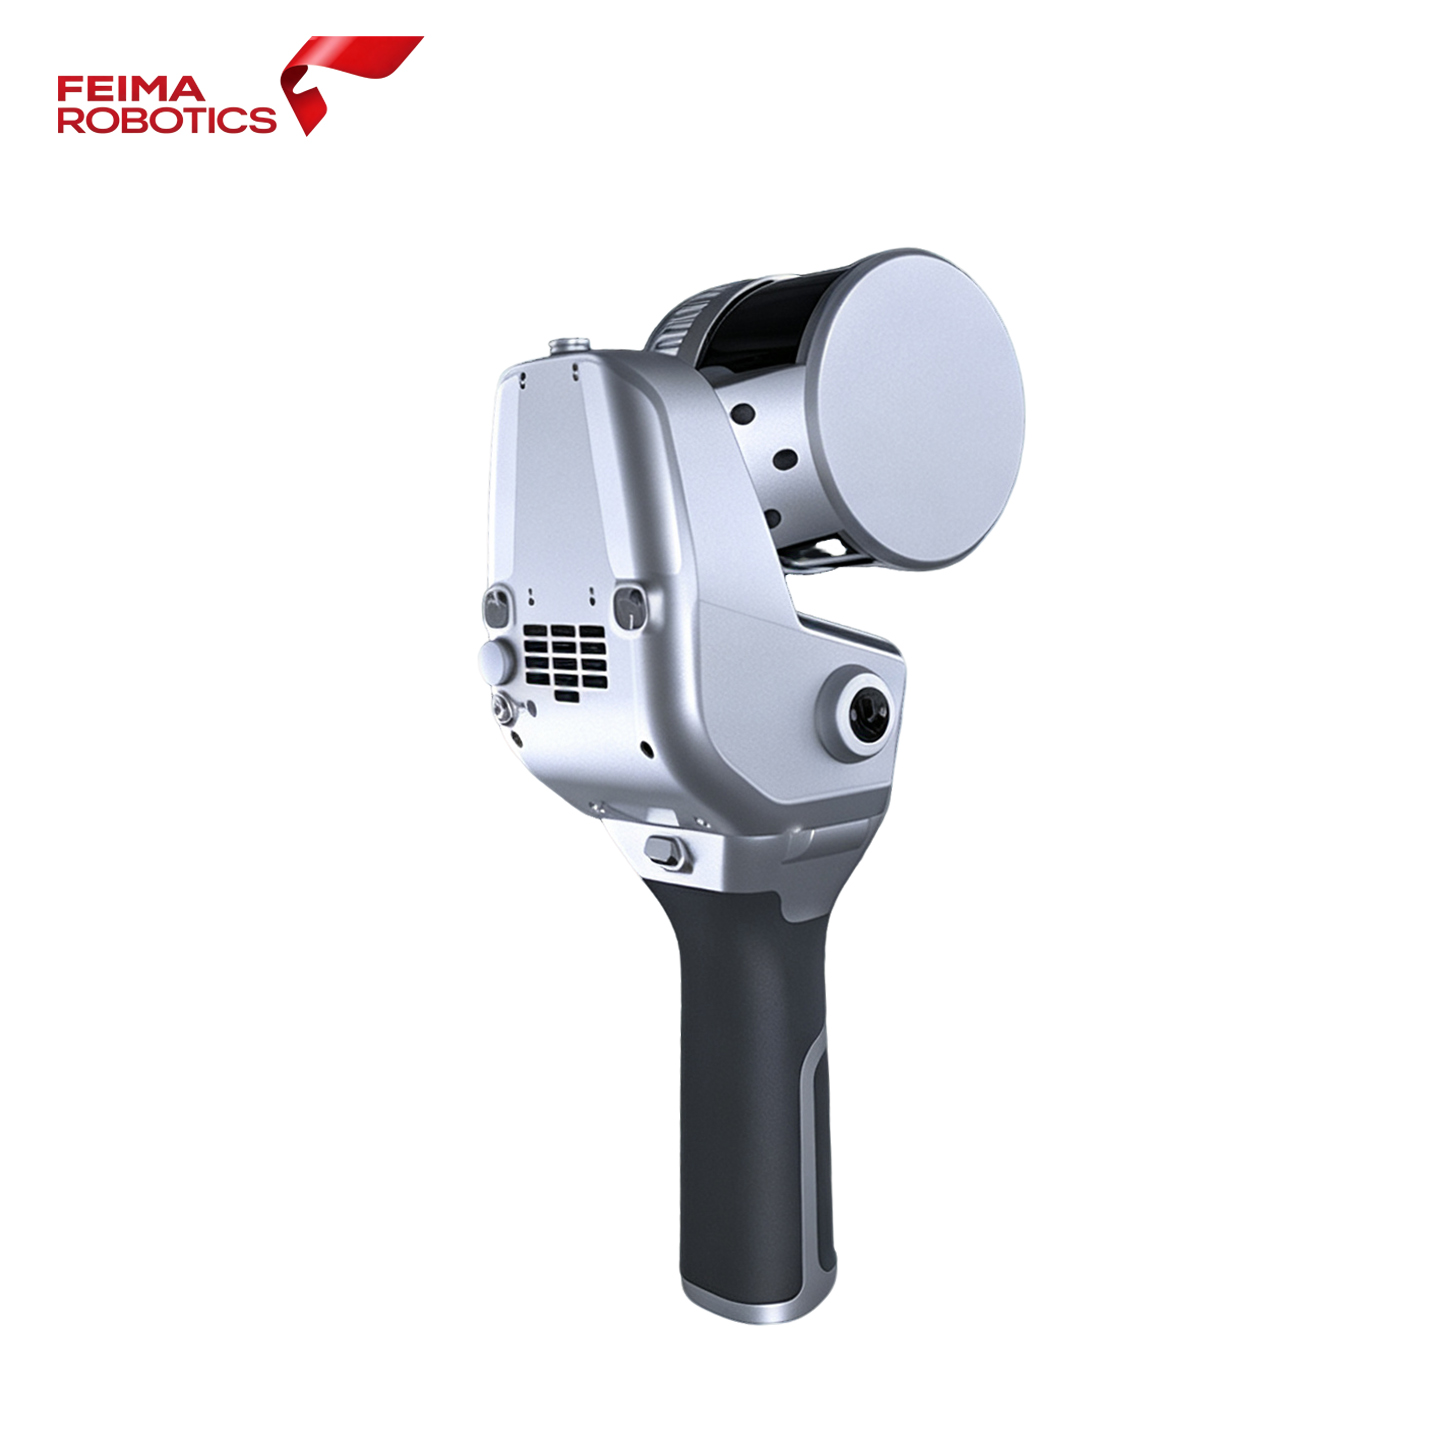
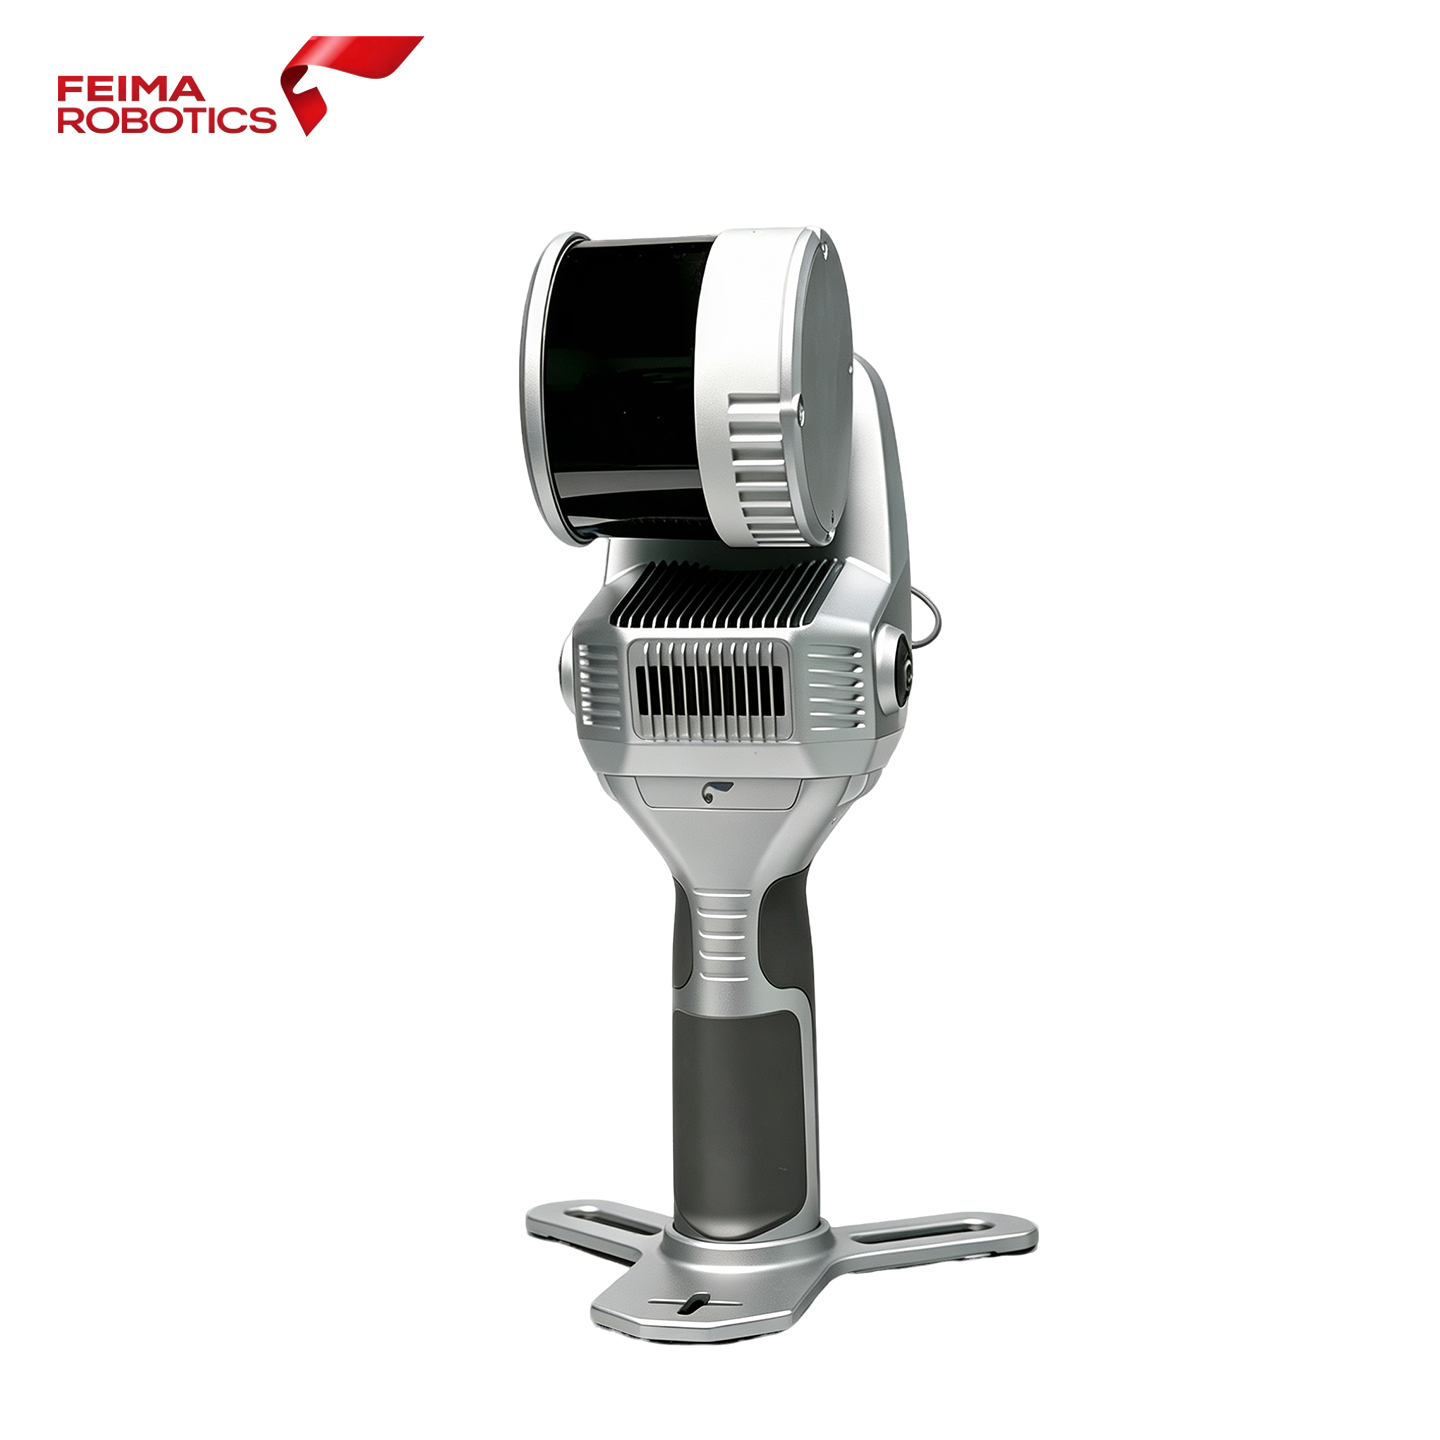
Feima SLAM200 Long Range Handheld SLAM LiDAR Scanner, 300m Large Scene 3D Mapping System
Core Advantages of SLAM200
300m Ultra Long Measuring Range
Suitable for high-rise facades, large factories and wide-area terrain survey, greatly improve field efficiency.
Built-in GNSS & RTK Support
Connect CORS network via mobile phone, output point cloud with absolute coordinates, absolute accuracy within 3cm.
640,000 Points/sec High Density
Small laser spot + deep learning point cloud refinement, capture tiny structural details clearly.
Dual 12MP Panoramic Cameras
Real-time point cloud colorization, generate realistic textured point cloud and panoramic images.
Real-time Mapping & Preview
Real-time SLAM reconstruction, on-site check point cloud quality without waiting post-processing.
Multi-platform Modular Mount
Freely switch between handheld, backpack, vehicle-mounted and UAV airborne survey modes.
-
PRODUCT DESCRIPTION
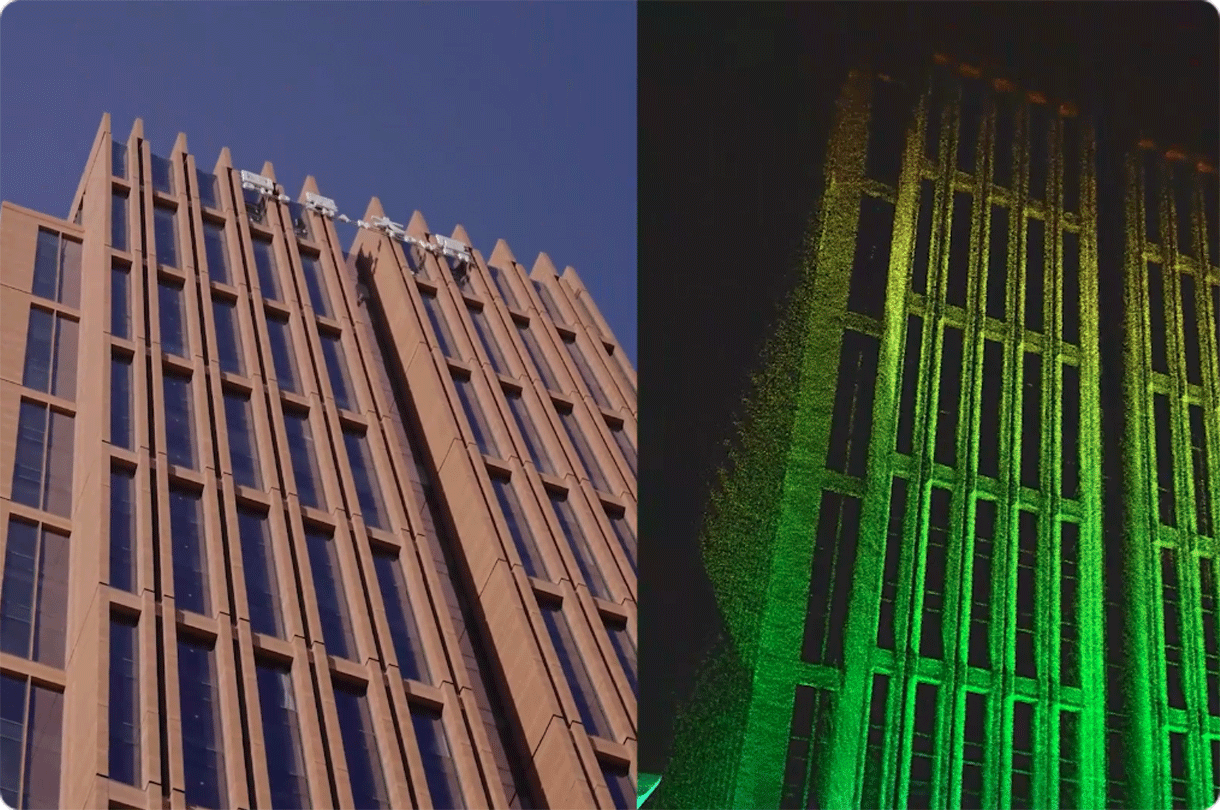
300m Long Scan Range
The 300-meter ultra-long range meets the needs of high-rise buildings, large factories, pavilions and other long-distance measurement requirments, and the sensor can cover a wider area, improve measurement efficiency, and reduce measurement costs.
-
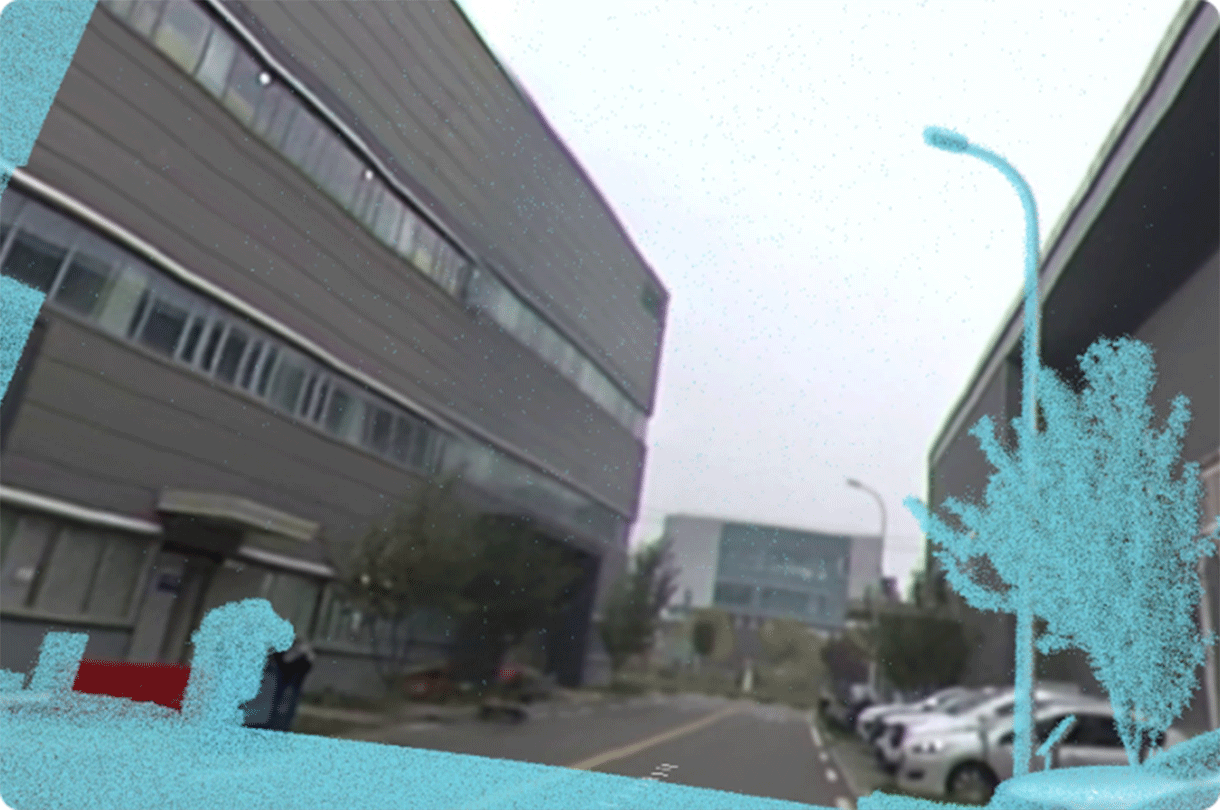
Panoramic camera
Dual 12 MP fisheye cameras can capture 360 degree wide field of view images and fine textures, generating more realistic color point clouds and panoramic images.
-
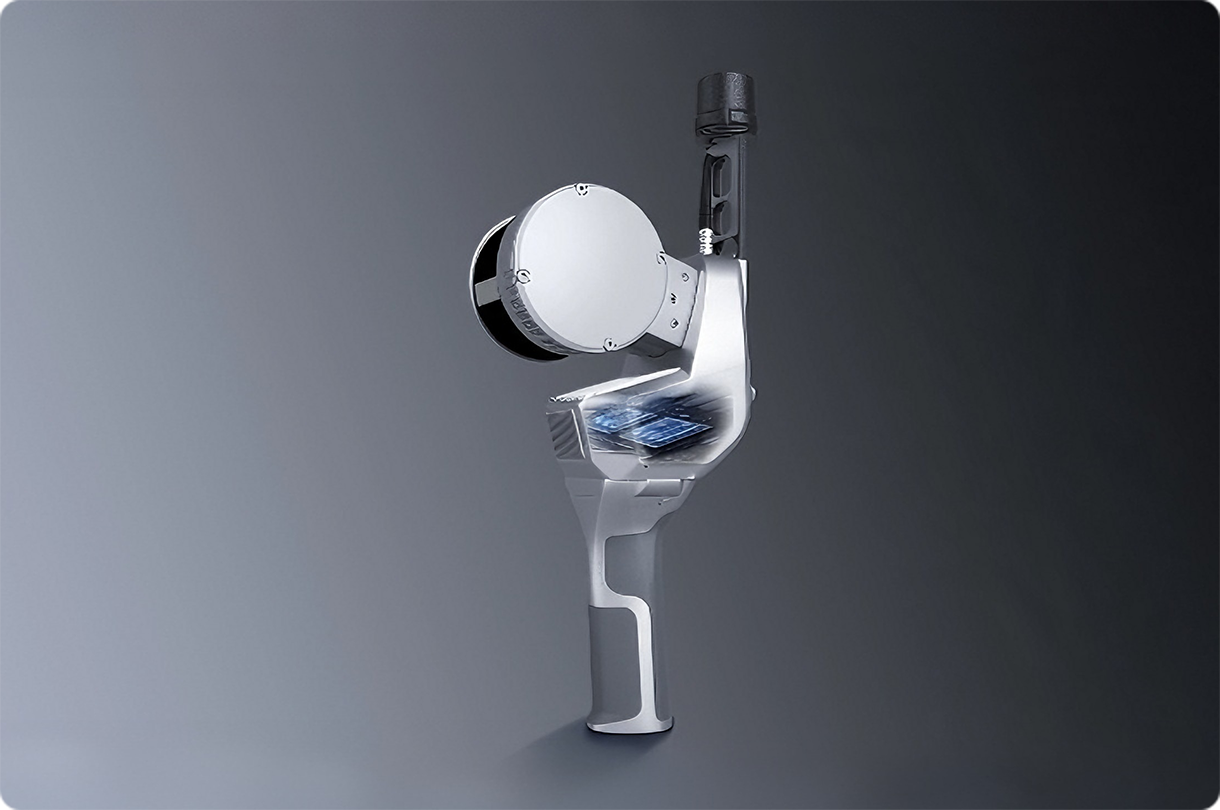
Built-in GNSS chip
With built-in GNSS chip and deeply integrated RTK technology, the centimeter level positioning accuracy always follows.
-
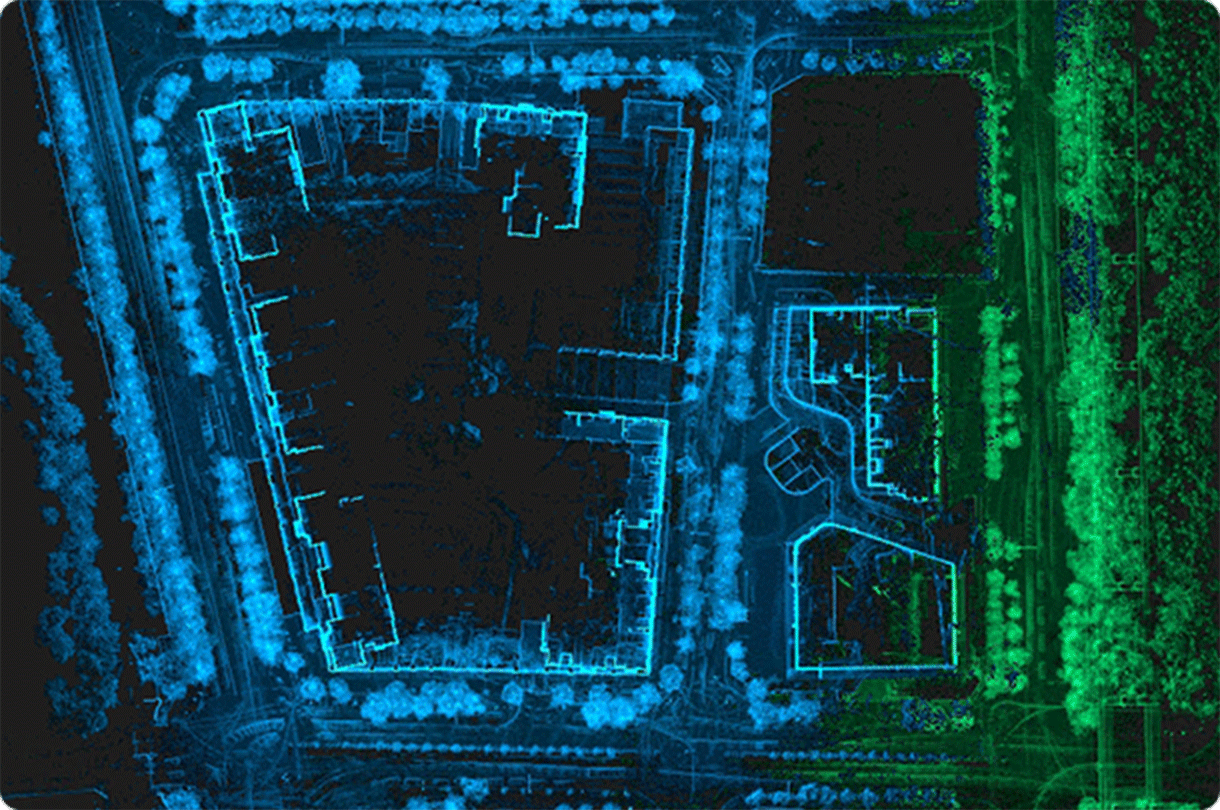
Breakpoint Scan Resume
Continious scan at breakpoint by orientation, non-orientation and mixed methods, fully adapts to the requirements of large-scale surveying areas. Adopting advanced overall point cloud registration algorithm, SLAM2000 can significantly enhance positioning accuracy and improve operational efficiency.
Long-Range High Precision Mobile Mapping
Optimized industrial SLAM algorithm ensures stable mapping both in open outdoor areas and semi-enclosed spaces.
- Max Measuring Distance: 300 m
- Point Frequency: Up to 640,000 points per second
- Absolute Accuracy: ≤ 3 cm with RTK / CORS connection
- Supports closed-loop correction to reduce SLAM cumulative error
- Real-time color point cloud output, directly export LAS/LAZ data
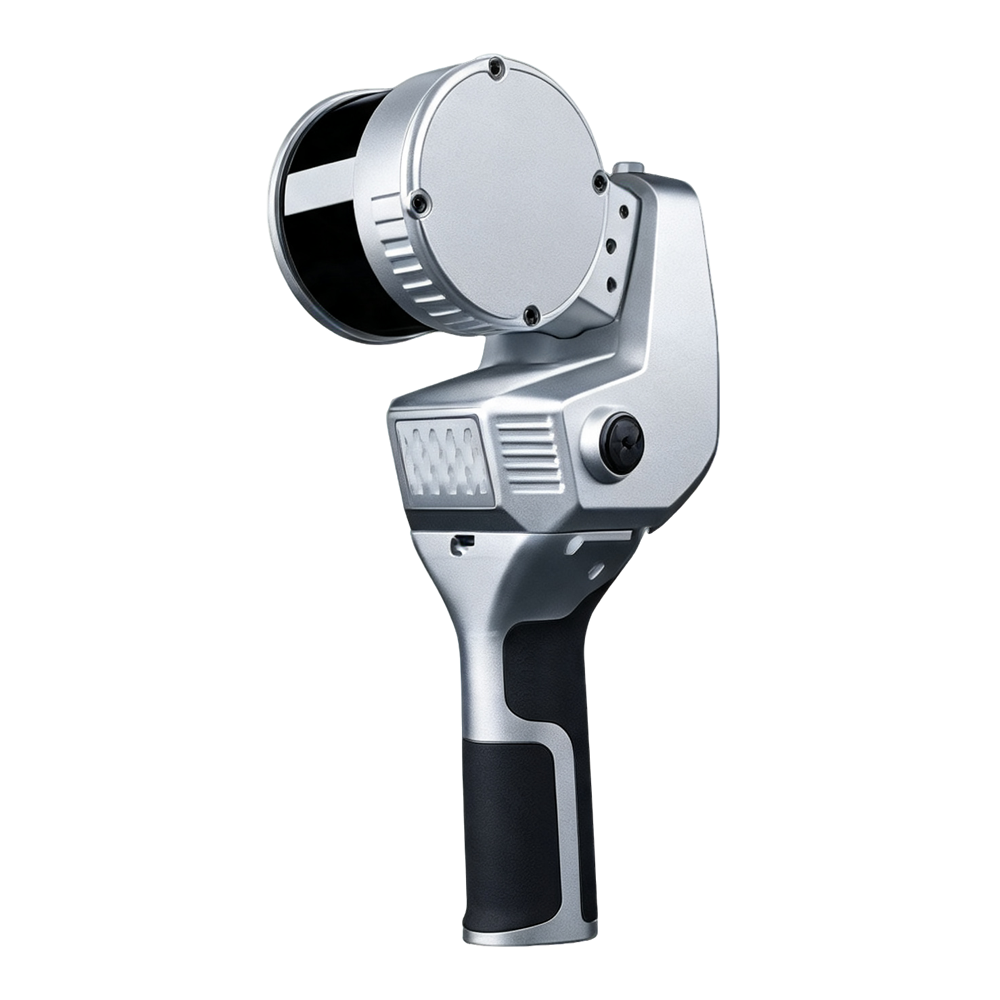
Multiple Working Modes
SLAM200 supports a modular cross-platform multi-task mode, enabling seamless switching across various applications such as drones, backpacks, static stations, and vehicle-mounted systems.
SLAM GO POST Pro
Official post-processing workstation for SLAM200, supporting raw data decoding, point cloud optimization, colorization, coordinate transformation and multi-format export.
High-quality Colorized Point Cloud Generation
Automatically match panoramic images with LiDAR data, generate true-color measurable point cloud.
Coordinate Conversion & RTK Data Fusion
Support seven-parameter transformation, fuse GNSS trajectory data to improve absolute positioning accuracy.
Diversified Data Export
Output LAS, LAZ, PLY, panoramic images; compatible with CAD, Revit, CloudCompare, Cyclone.
Point Cloud Editing & Measurement
Denoising, clipping, thinning, distance, area and earthwork volume measurement inside software.
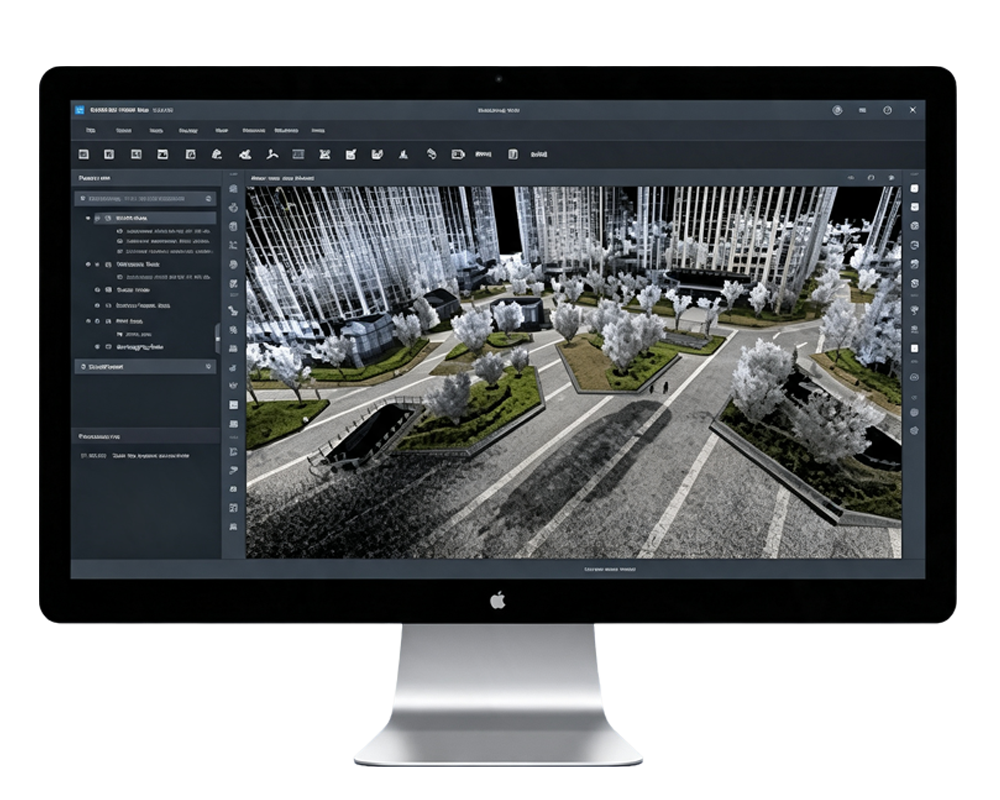
Wide Range of Industry Applications
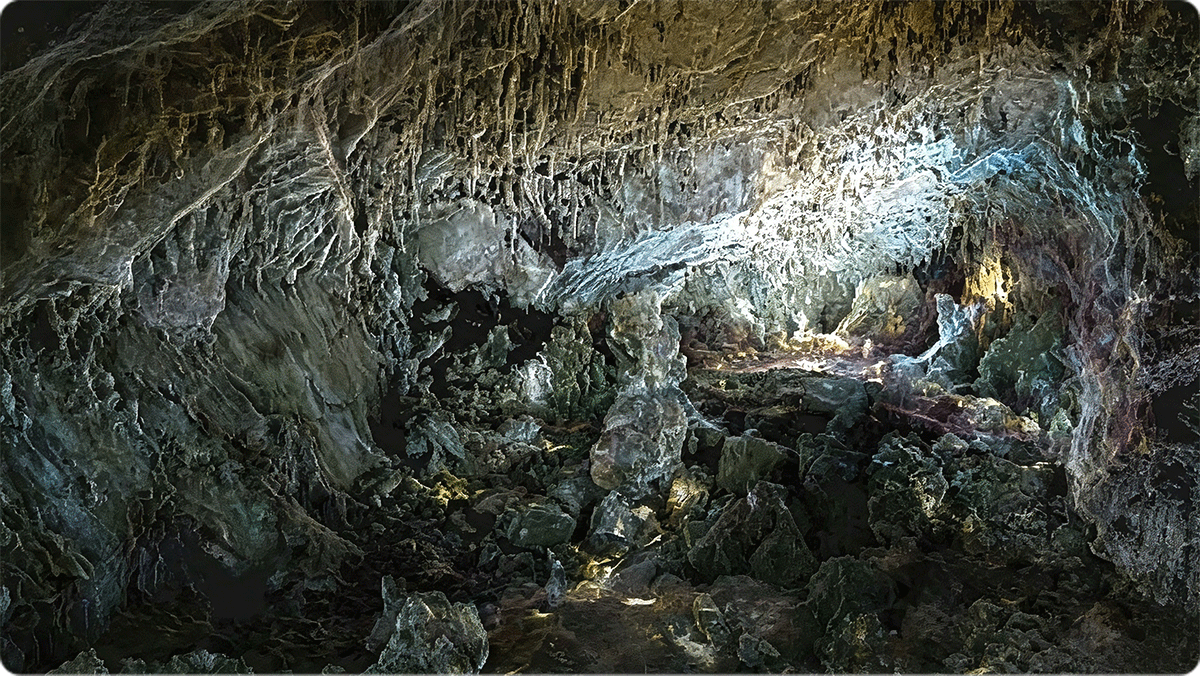
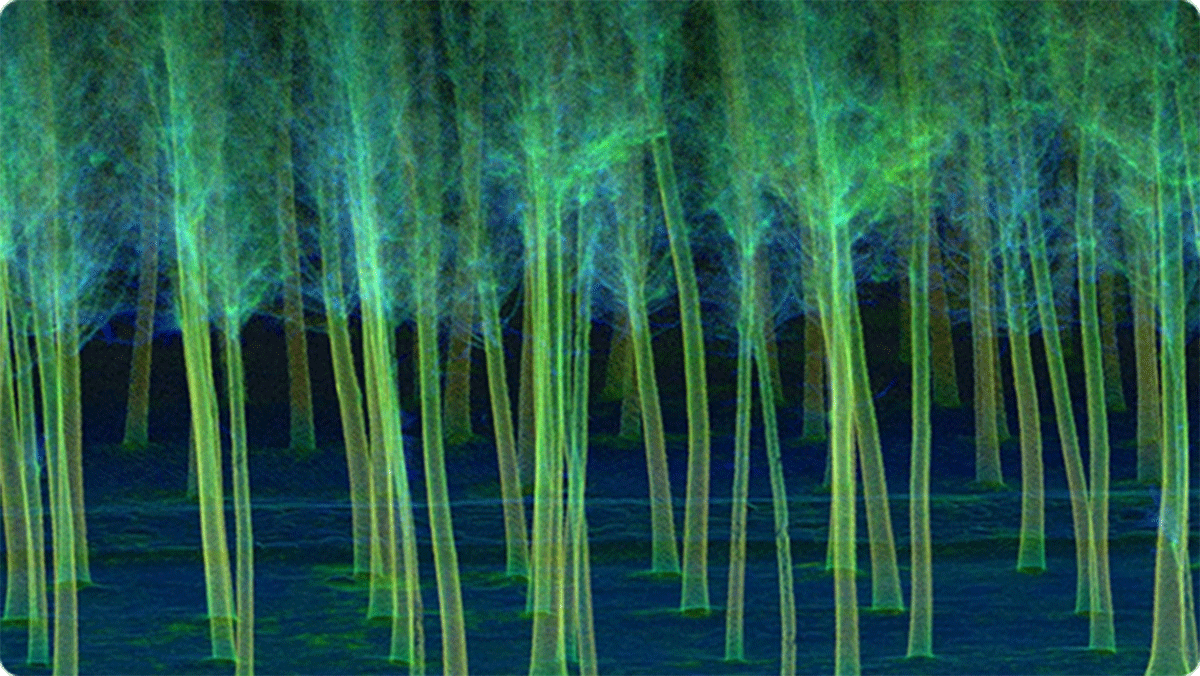
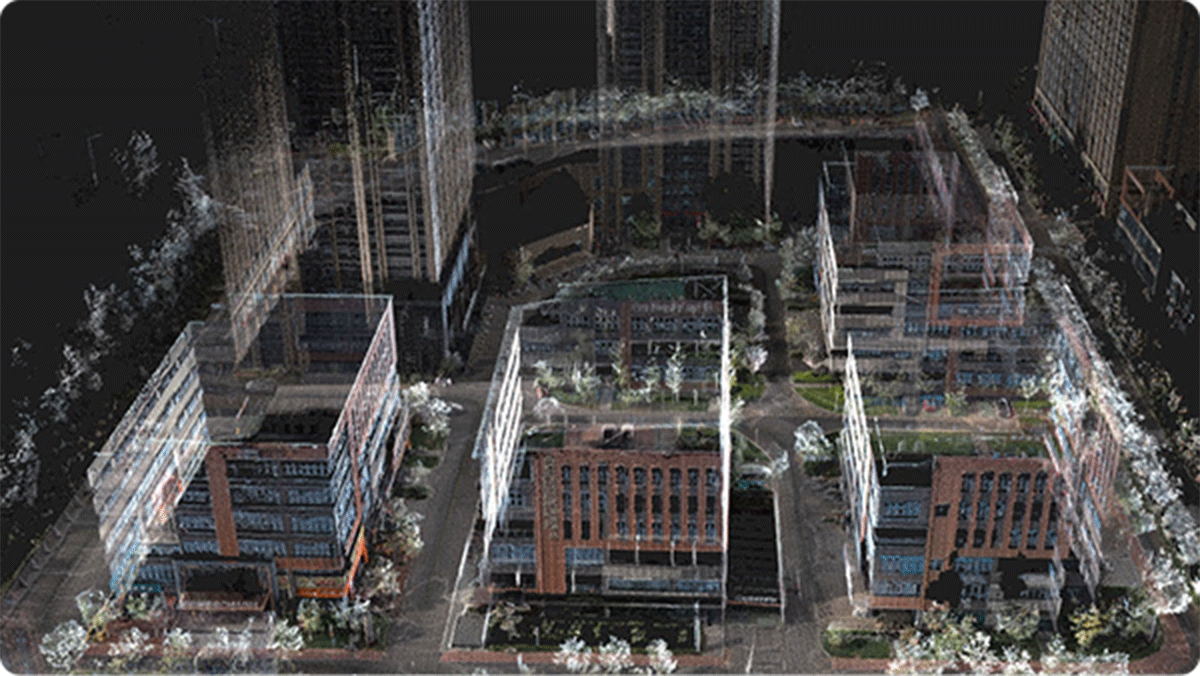
SLAM200
Handheld Laser Scanner — Technical Specifications
Main Body
| Parameter | Specification |
|---|---|
| Weight | 1.4 kg (Host) / 1.9 kg (With battery handle, base) |
| Dimensions | 403.6 mm × 137.8 mm × 170 mm |
| Internal Data Storage | 512 GB SSD |
| Working Temperature | -20 ℃ ~ 50 ℃ |
| Humidity | < 95% |
| Protection Class | IP54 |
| Communication | Type-C / Bluetooth / Wi-Fi |
| Lithium Battery Handle | SP30 |
| Lithium Battery Weight | 400 g |
| Lithium Battery Endurance | Approx. 70 mins (Only SLAM200) |
Camera
| Parameter | Specification |
|---|---|
| Number of Cameras | 2 |
| Effective Pixels | 12 MP (per camera) |
| Resolution | 4000 (H) × 3000 (V) (per camera) |
| FOV | 210° (per camera) |
| Frame Rate | 30 Hz |
Result Accuracy
| Parameter | Specification |
|---|---|
| Point Cloud Thickness | 0.5 cm (After optimization) |
| Relative Accuracy | 5 mm @ 60 m / 1 cm @ 100 m |
| Absolute Accuracy | 3 cm |
| FOV | 210° (per camera) |
GNSS Module
| Parameter | Specification |
|---|---|
| Satellite System | GPS / GLONASS / Galileo / BDS / QZSS |
| Positioning Accuracy (RTK) | Horizontal: 0.8 cm + 1 ppm / Vertical: 1.5 cm + 1 ppm |
Laser
| Parameter | Specification |
|---|---|
| Laser Class | Class 1 |
| FOV | 360° (H), 270° (V) |
| Rotating Rate | 10 Hz (Typical) |
| Range | 0.5 m ~ 300 m |
| Laser Pulse Repetition Rate | 640 kpts/s |
IMU
| Parameter | Specification |
|---|---|
| Bias Instability | 0.5°/h (Allan Variance @ 25 ℃) |
| Angle Random Walk | 0.025°/√hr |