
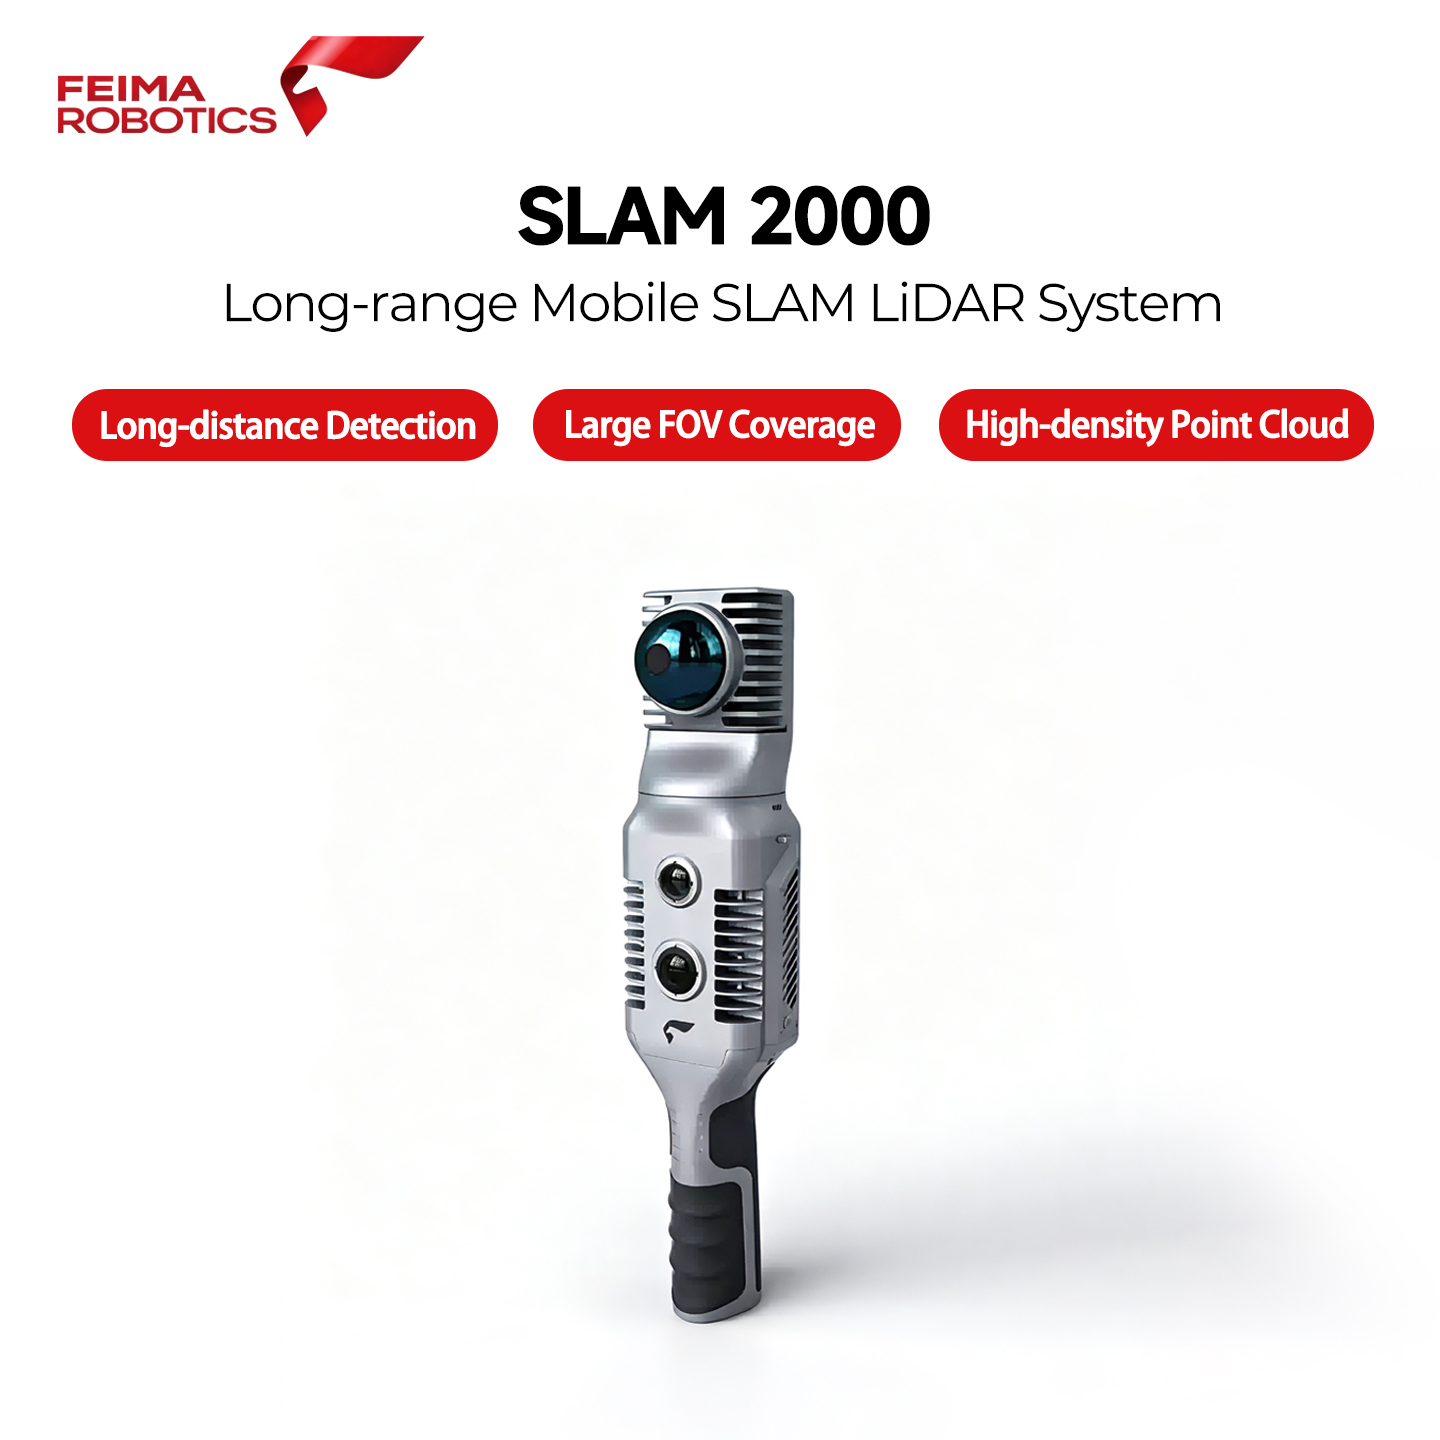
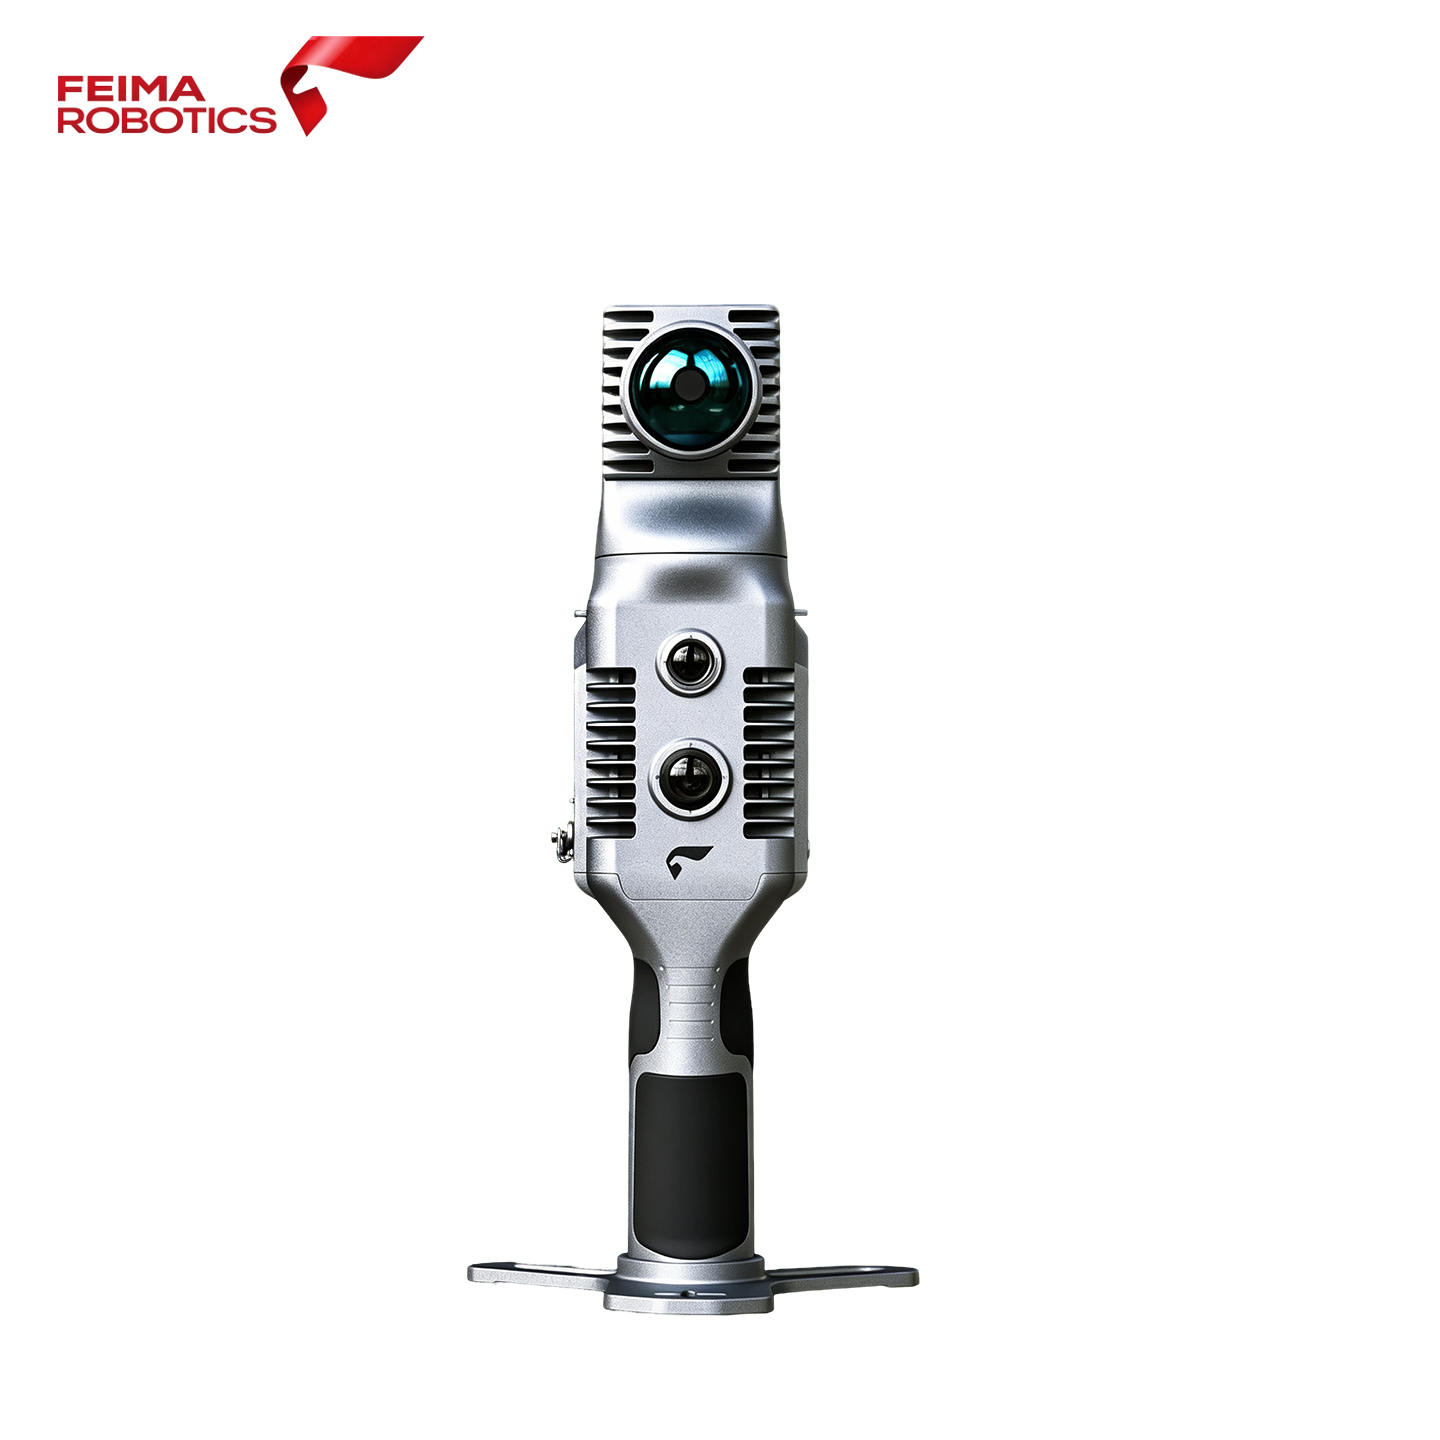
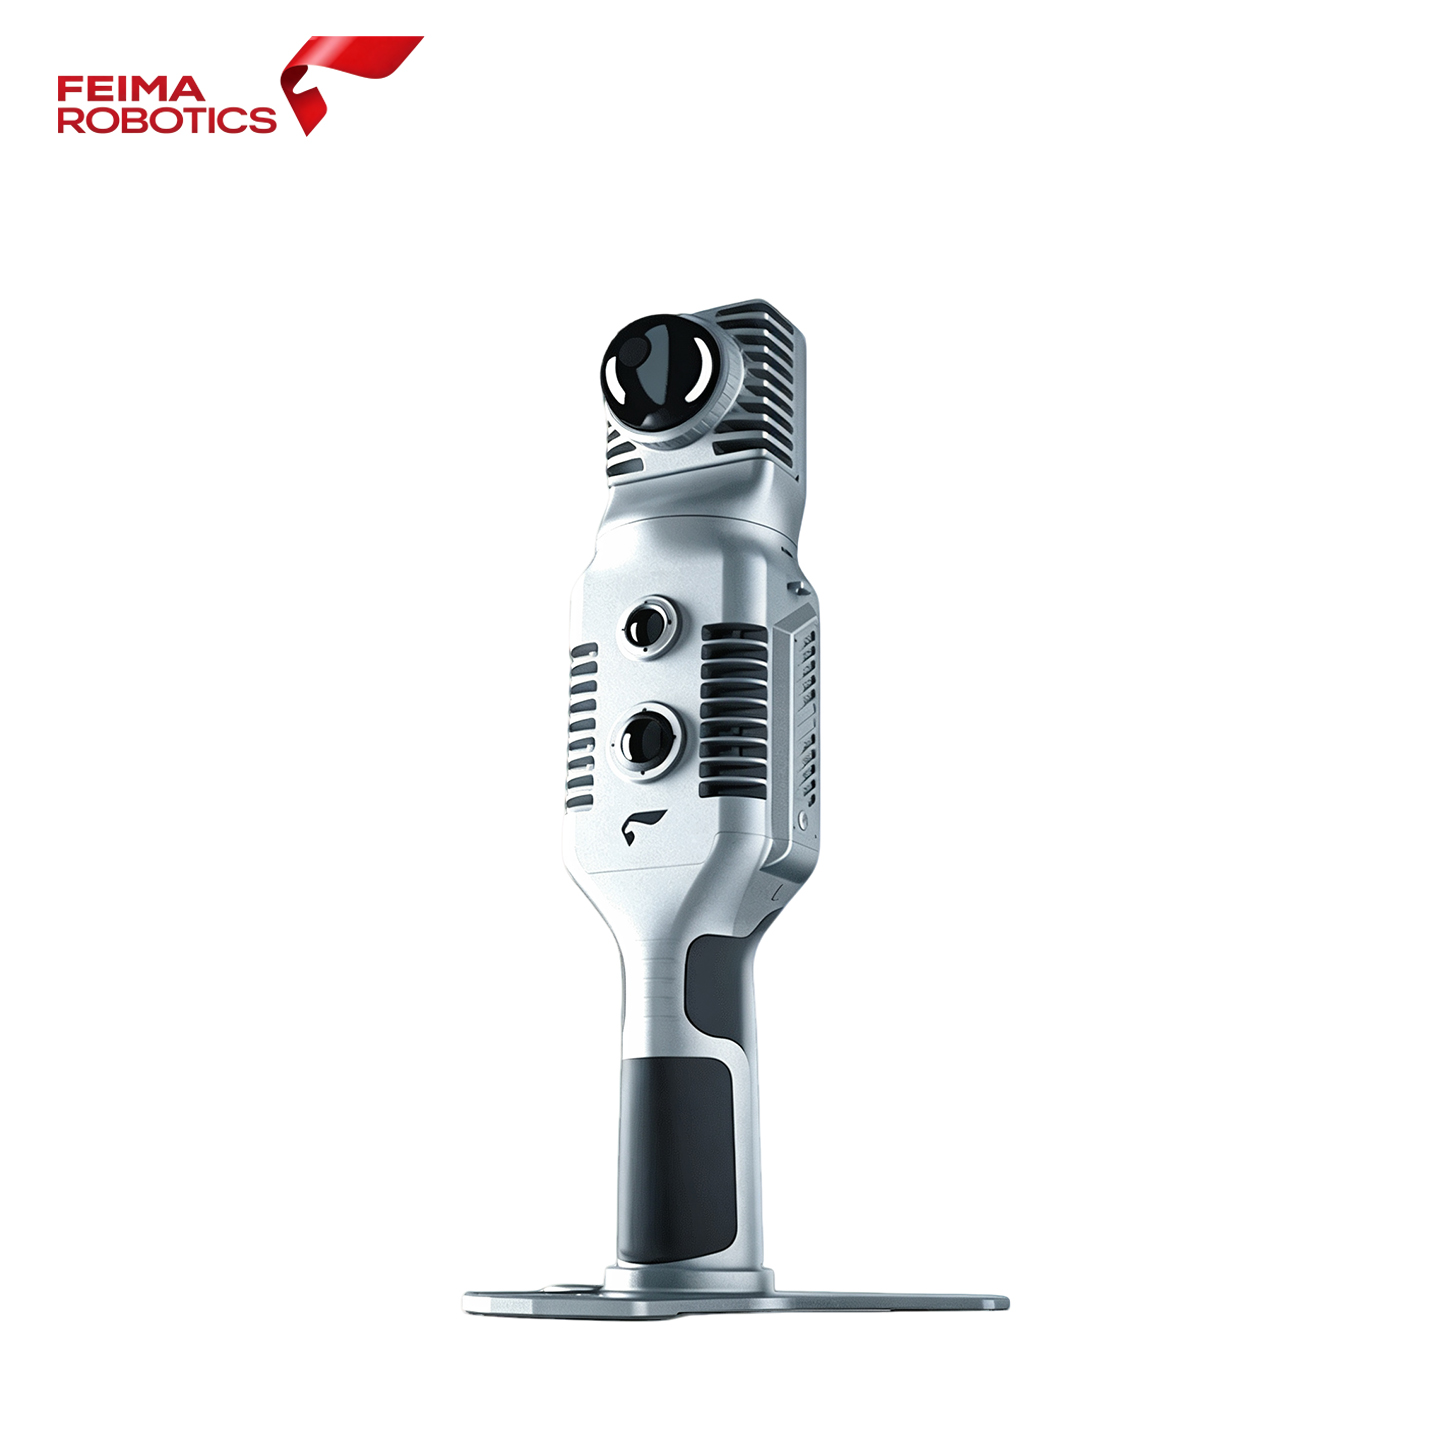
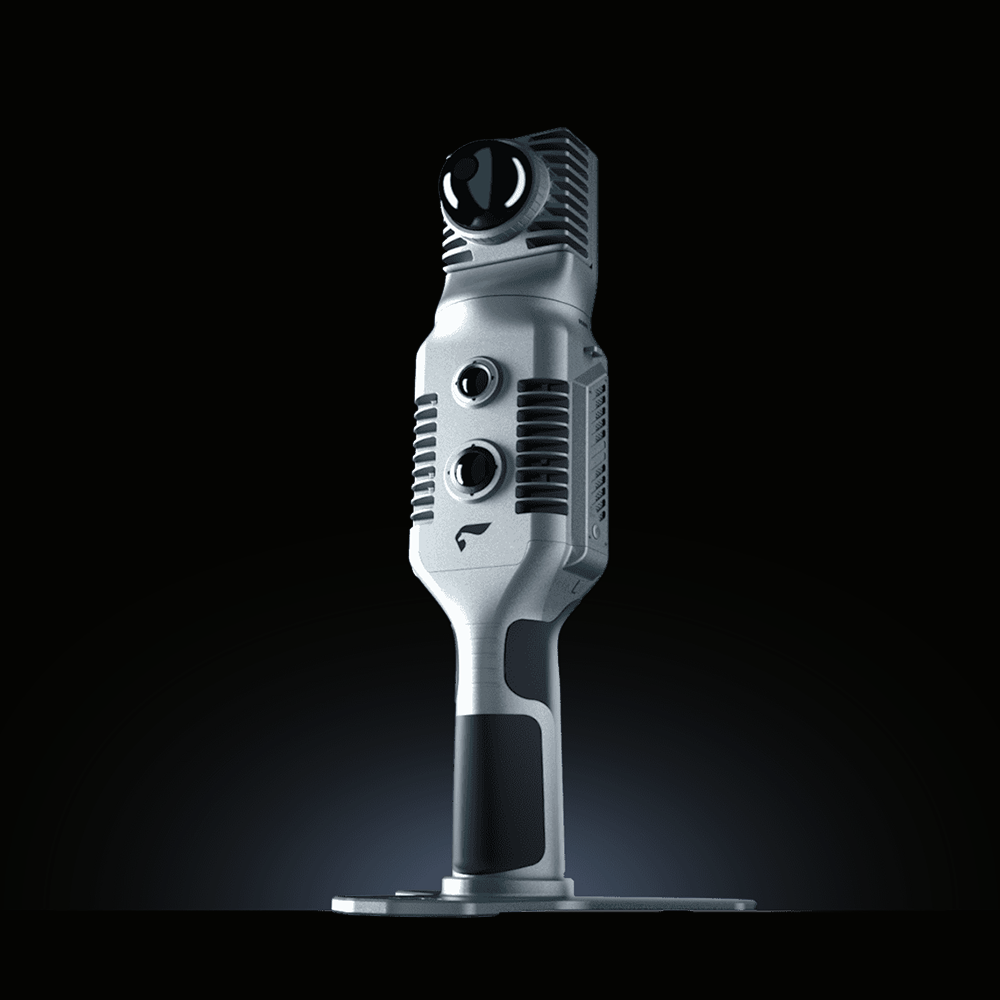
Feima SLAM2000 Handheld LiDAR Scanner, 720° Panoramic Real-Time 3D Mapping System
Core Advantages of SLAM2000
Hemispherical Non-repetitive Scanning
360° rotating gimbal realizes full-space coverage, uniform point cloud distribution without repeated scanning trajectory.
Dual 12MP 1-inch CMOS Cameras
Independent texture camera + visual SLAM camera, improve stability in weak-texture indoor scenes.
Multi-mode Operation Supported
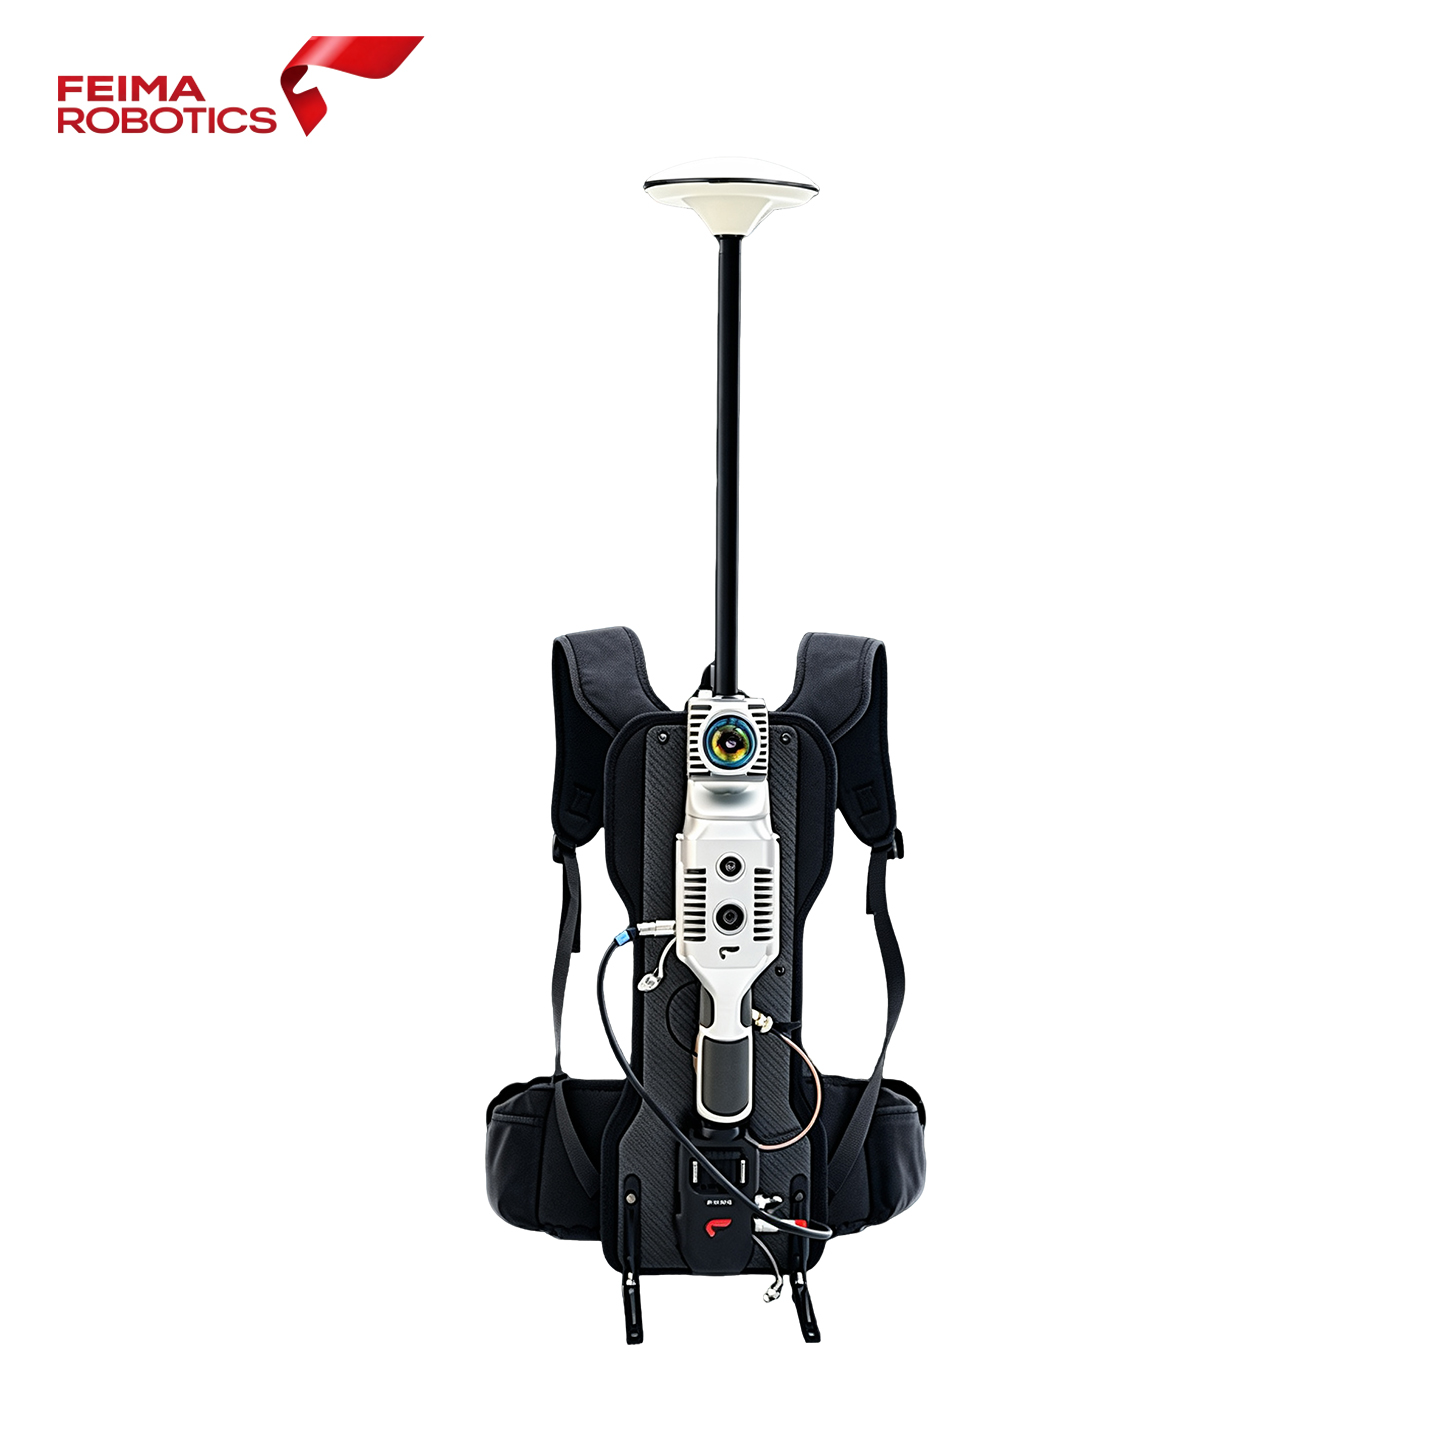
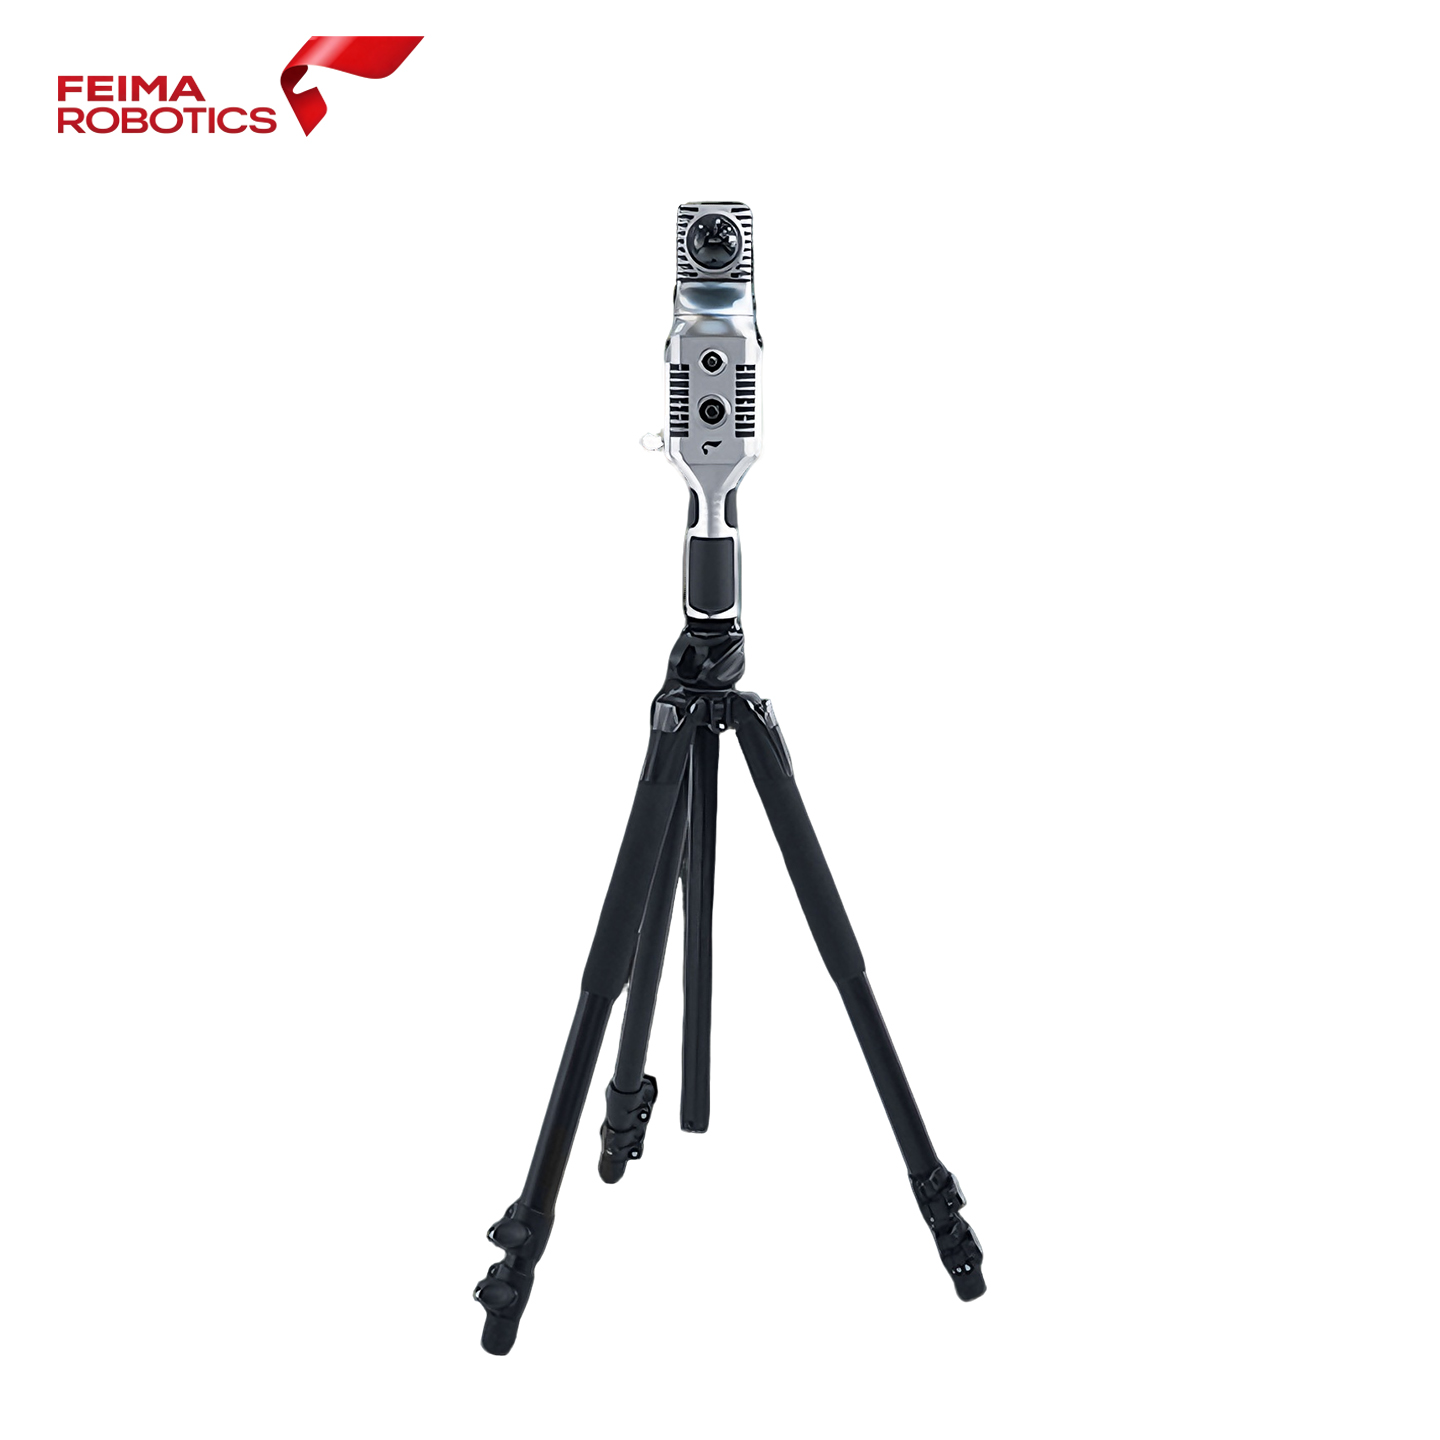
Handheld, backpack mobile scanning, plus tripod stationary mode for ultra-fine static point cloud acquisition.
High Precision Built-in IMU
Optimize cumulative error control; post-processing relative accuracy ≤1cm for high-quality reconstruction.
Real-time On-site Reconstruction
Preview point cloud results during scanning, avoid missing data and support on-site quality inspection.
512GB Built-in SSD Storage
High-speed local storage, stable data writing, support long-time continuous acquisition.
Survey-grade Precision for Fine 3D Mapping
Fusion LiDAR SLAM + Visual SLAM algorithm, effectively suppress drift in corridors, warehouses and tunnel-like weak-feature environments.
- Effective Measuring Distance: 0.1m ~ 70m
- Laser Point Rate: 200,000 points per second
- Post-processing Relative Accuracy ≤ 1 cm
- Real-time Point Cloud Thickness ≤ 2 cm
- Support loop closure optimization and trajectory adjustment
- Export LAS / LAZ / PLY compatible with BIM & modeling software
-
PRODUCT DESCRIPTION
-
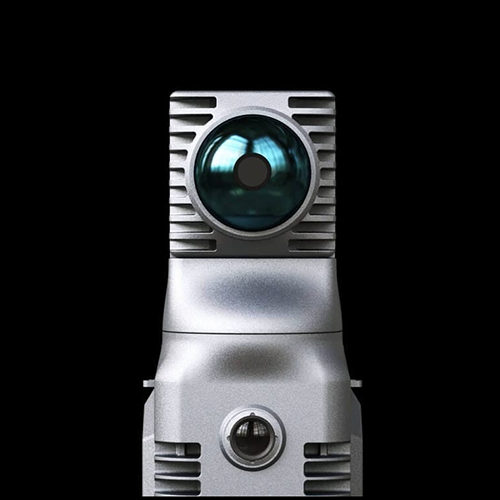
Visual camera
SLAM2000 adopts a 12MP visual camera to run visual SLAM algorithms. It supplies feature points for low-texture environments, reduces errors caused by repetitive structures and mismatching, and expands scene adaptability. Meanwhile, the visual camera captures high-definition local scene images.
-
Self-developed INS Chip
Equipped with self-developed high-precision inertial navigation chip, SLAM2000 suppresses data cumulative errors. Optimized radar calibration and upgraded industrial SLAM algorithms enable fast generation of high-precision 3D data in multiple environments.
-
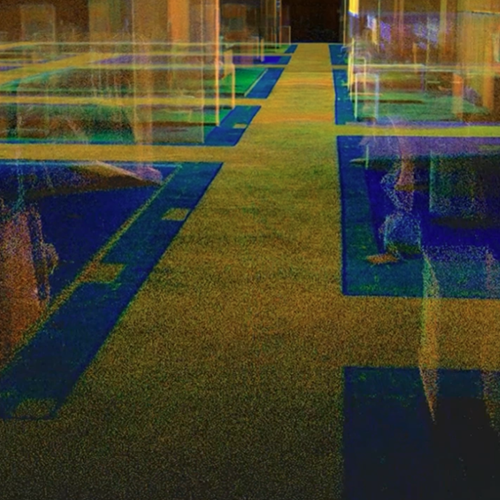
Dense Color Pointcloud
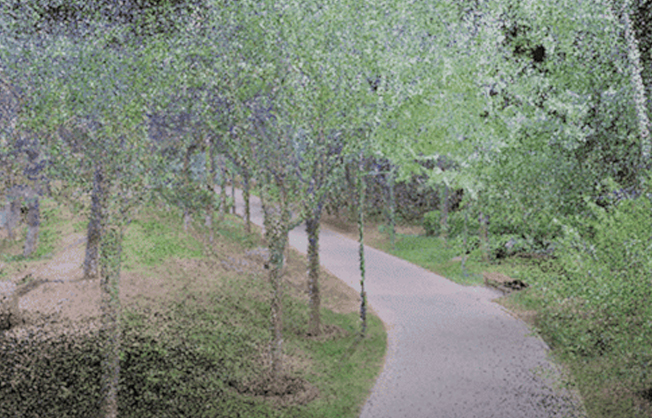
Generates high‑density georeferenced colored point clouds with rich texture details. Fine features of buildings and facilities can be clearly restored for high‑precision digital reconstruction.
-
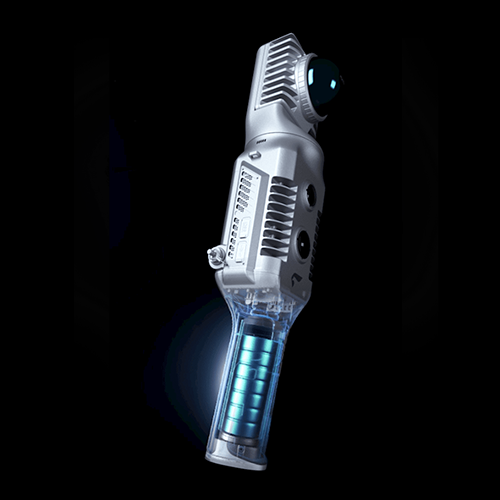
Smart Battery Handle
SLAM2000 uses a safer 3000mAh replaceable intelligent battery handle, which can ensure that SLAM2000 works continuously and stably for 95 minutes. It charges with a Type-C interface and is equipped with a standard 65W fast charging device to ensure power supply.
Multiple Working Modes
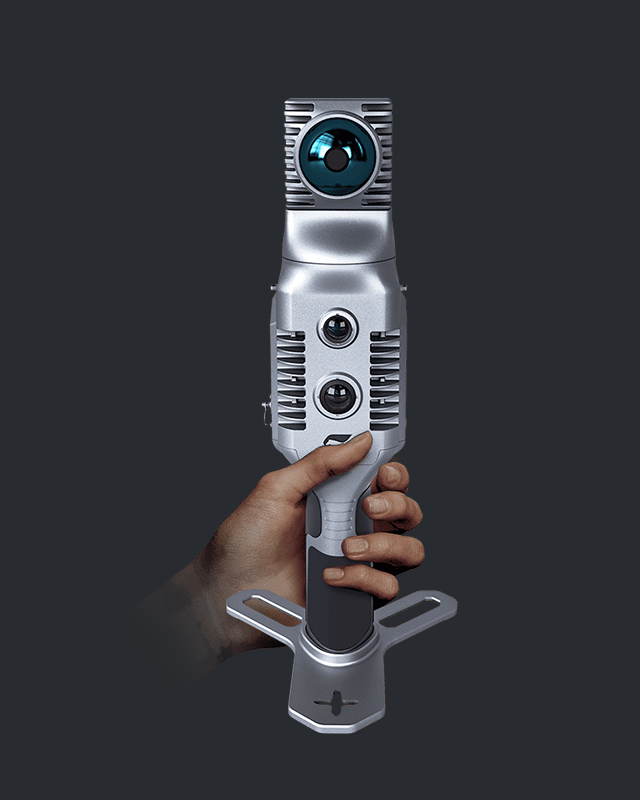
Handheld Mobile Mode
Indoor buildings, shopping malls, underground parking continuous walking scanning
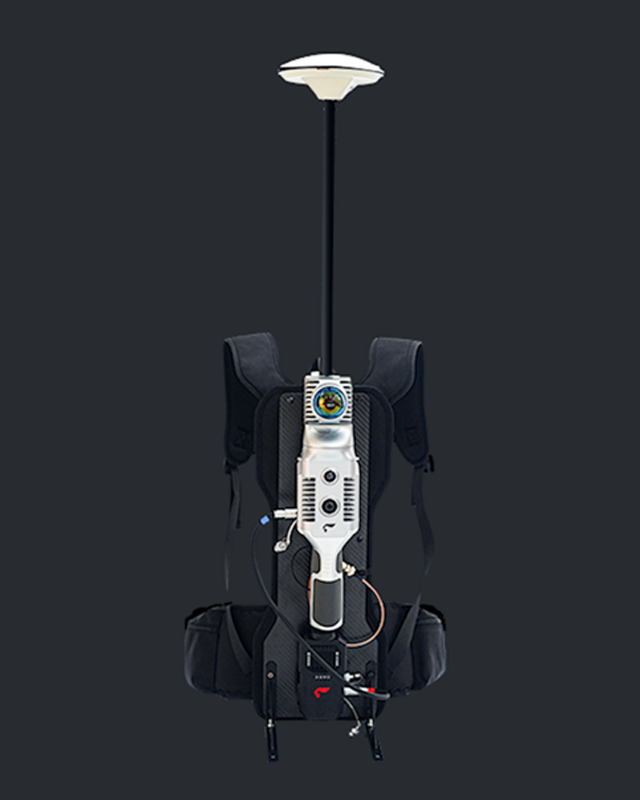
Backpack Mode
Large factory workshop, long corridor, underground pipe gallery survey
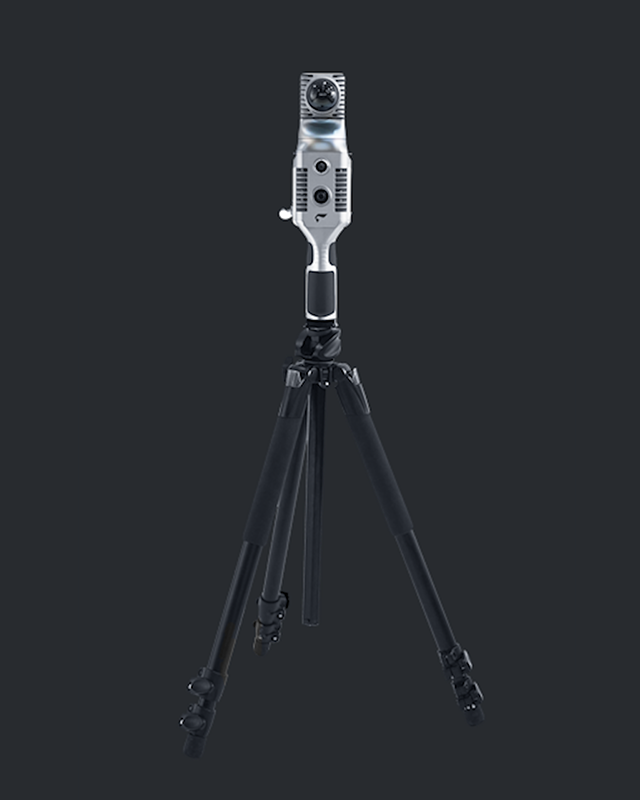
Tripod Stationary Mode
High-density static scanning for cultural relics, sculptures, detailed facades
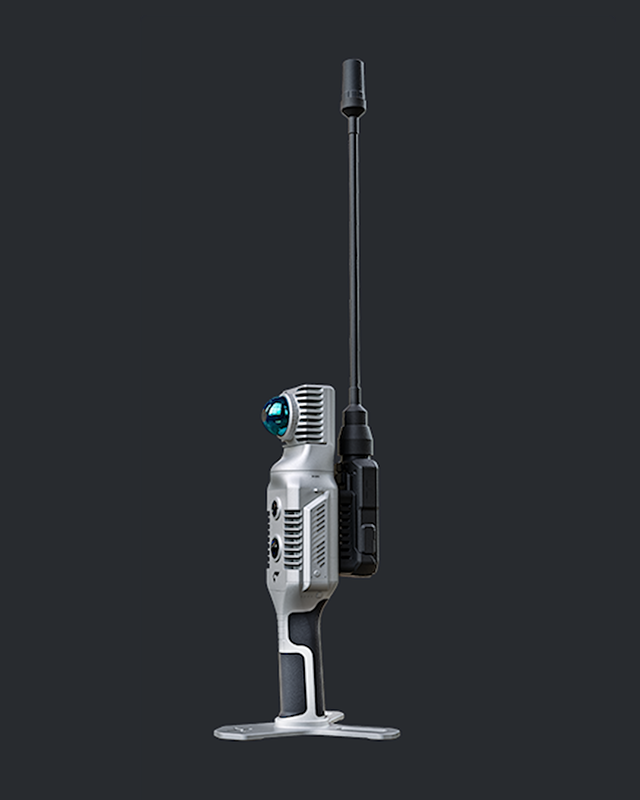
External S-RTK Optional
Small outdoor scene georeferencing, improve absolute positioning accuracy
Supporting Software
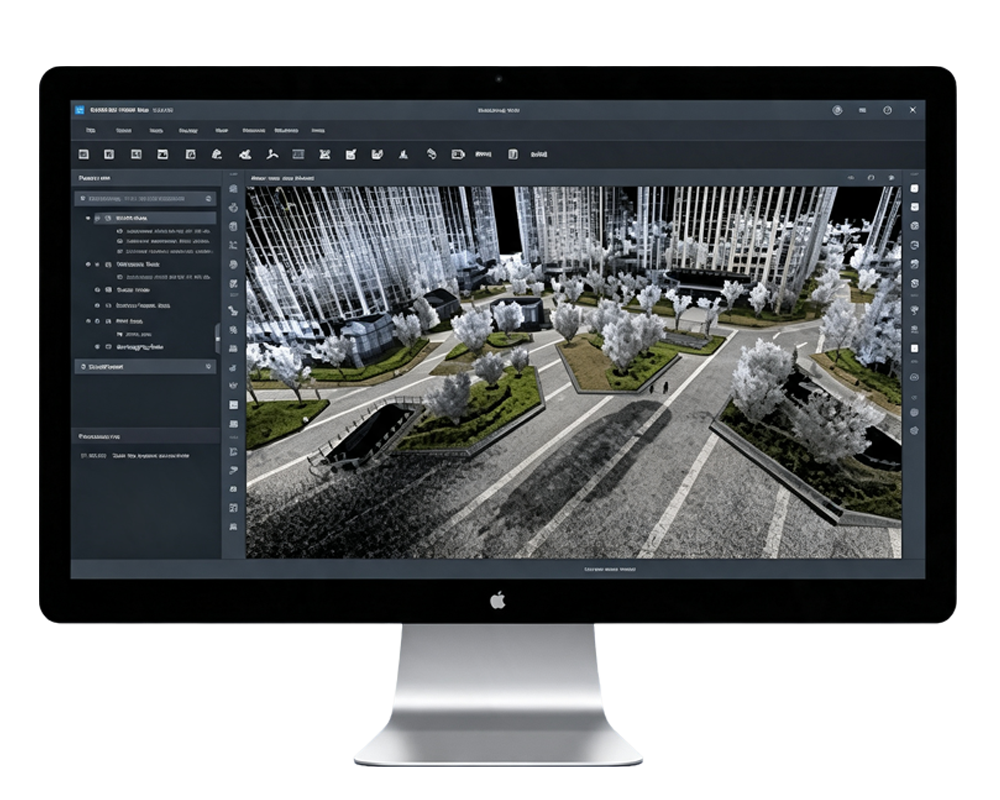
SLAM GO POST Pro is a professional PC-end data processing software specifically designed for Pocket3D. It is equipped with its own core data processing algorithm and supports the one-click generation ofpoint cloud, panoramic images, and Gaussian model results. It integrates a ful-process tool for resultbrowsing, visualization display, precise measurement, and interest point annotation. At the same time, itcan complete the unified management, batch processing, and fusion combination of multiple measure-ment data, and complete the post-processing of 3D data in one step.
High-Fidelity 3DGS Model Construction
Without relying on the SFM algorithm, it accurately recovers the pose of panoramic images in complex environments and generates high-quality Gaussian model data.
High-Precision Point Cloud Map Construction
Supporting the generation of indoor and outdoor colored point clouds with a relative accuracy of up to 2 cm.
High-Resolution Panoramic Image Stitching
Supporting the processing of original panoramic camera data, stitching high-resolution panoramic images with pose information, and achieving precise matching between panoramic images and point clouds.
Compatibility with Third-Party Modeling Software
It can output each frame of panoramic camera images and calibrated pose elements. It can also output standard Colmap-format data processed by the built-in SFM algorithm, compatible with mainstream or self-developed third-party modeling software such as MipMap and Postshot.
Result Browsing
Supporting the browsing and editing of point cloud data and 3DGS data results.
Note: Colored point clouds, panoramic images, and 3DGS models require an optional external camera.
Wide Range of Industry Applications
SLAM2000
Handheld Laser Scanner — Technical Specifications
Main Body
| Parameter | Specification |
|---|---|
| Weight | 925 g (Host) / 1450 g (With handle and base) |
| Dimensions | 94.5 mm × 84.6 mm × 219 mm (Host) / 170 mm × 173.8 mm × 364.5 mm (With handle and base) |
| Power Consumption | 20 W (Typical) |
| Input Voltage | 20 V |
| Internal Storage | 512 GB SSD |
| Working Temperature | -20 ℃ ~ 50 ℃ (Operation), -40 ℃ ~ 70 ℃ (Storage) |
| Humidity | < 95% |
| Protection Class | IP54 |
| Scanning FOV | Panoramic 360° |
Accuracy
| Parameter | Specification |
|---|---|
| Point Cloud Thickness | 1 cm (Post-processing), 2 cm (Real-time) |
| Relative Accuracy | 2 cm (Post-processing), 3 cm (Real-time) |
| Absolute Accuracy | 5 cm (Post-processing) |
Laser Scanner
| Parameter | Specification |
|---|---|
| Wavelength | 905 nm |
| Laser Class | Class 1 |
| Range | 0.1 m ~ 70 m @ 80% |
| FOV | 360° (H), -7° ~ 52° (V) |
| Laser Pulse Repetition Rate | 200 kHz |
| Echo | Single (Strongest) |
| Frame Rate | 10 Hz (Typical) |
Texture Camera
| Parameter | Specification |
|---|---|
| Resolution | 12 MP |
| FOV | 210° (Diagonal) |
| Frame Rate | 30 Hz |
Visual Camera
| Parameter | Specification |
|---|---|
| Resolution | 12 MP |
| FOV | 100° (Diagonal) |
Interface
| Parameter | Specification |
|---|---|
| USB Type-C1 | SSD data copy |
| USB Type-C2 | Charge by PD power bank, OTG (5V) |
| Circular Connector | External power supply (20 V), External S-RTK |
| WiFi | Supported |
Intelligent Battery
| Parameter | Specification |
|---|---|
| Model | SP30 |
| Input Voltage | 5 V - 20 V |
| Output Voltage | 10.8 V |
| Battery Capacity | 3000 mAh |
| Weight | 400 g |
| Dimensions | 85 mm × 60 mm × 144.5 mm |
| Endurance | Approx 95 mins (SLAM2000 only) |
Core Advantages of SLAM2000
Hemispherical Non-repetitive Scanning
360° rotating gimbal realizes full-space coverage, uniform point cloud distribution without repeated scanning trajectory.
Dual 12MP 1-inch CMOS Cameras
Independent texture camera + visual SLAM camera, improve stability in weak-texture indoor scenes.
Multi-mode Operation Supported
Handheld, backpack mobile scanning, plus tripod stationary mode for ultra-fine static point cloud acquisition.
High Precision Built-in IMU
Optimize cumulative error control; post-processing relative accuracy ≤1cm for high-quality reconstruction.
Real-time On-site Reconstruction
Preview point cloud results during scanning, avoid missing data and support on-site quality inspection.
512GB Built-in SSD Storage
High-speed local storage, stable data writing, support long-time continuous acquisition.
Survey-grade Precision for Fine 3D Mapping
Fusion LiDAR SLAM + Visual SLAM algorithm, effectively suppress drift in corridors, warehouses and tunnel-like weak-feature environments.
- Effective Measuring Distance: 0.1m ~ 70m
- Laser Point Rate: 200,000 points per second
- Post-processing Relative Accuracy ≤ 1 cm
- Real-time Point Cloud Thickness ≤ 2 cm
- Support loop closure optimization and trajectory adjustment
- Export LAS / LAZ / PLY compatible with BIM & modeling software
-
PRODUCT DESCRIPTION
-
![DESCRIPTION-1]()
Visual camera
SLAM2000 adopts a 12MP visual camera to run visual SLAM algorithms. It supplies feature points for low-texture environments, reduces errors caused by repetitive structures and mismatching, and expands scene adaptability. Meanwhile, the visual camera captures high-definition local scene images.
-
![DESCRIPTION-2]()
Self-developed INS Chip
Equipped with self-developed high-precision inertial navigation chip, SLAM2000 suppresses data cumulative errors. Optimized radar calibration and upgraded industrial SLAM algorithms enable fast generation of high-precision 3D data in multiple environments.
-
![DESCRIPTION-3]()
Dense Color Pointcloud
Generates high‑density georeferenced colored point clouds with rich texture details. Fine features of buildings and facilities can be clearly restored for high‑precision digital reconstruction.
-
![DESCRIPTION-4]()
Smart Battery Handle
SLAM2000 uses a safer 3000mAh replaceable intelligent battery handle, which can ensure that SLAM2000 works continuously and stably for 95 minutes. It charges with a Type-C interface and is equipped with a standard 65W fast charging device to ensure power supply.
Multiple Working Modes
Handheld Mobile Mode
Indoor buildings, shopping malls, underground parking continuous walking scanning
Backpack Mode
Large factory workshop, long corridor, underground pipe gallery survey
Tripod Stationary Mode
High-density static scanning for cultural relics, sculptures, detailed facades
External S-RTK Optional
Small outdoor scene georeferencing, improve absolute positioning accuracy
Supporting Software
SLAM GO POST Pro is a professional PC-end data processing software specifically designed for Pocket3D. It is equipped with its own core data processing algorithm and supports the one-click generation ofpoint cloud, panoramic images, and Gaussian model results. It integrates a ful-process tool for resultbrowsing, visualization display, precise measurement, and interest point annotation. At the same time, itcan complete the unified management, batch processing, and fusion combination of multiple measure-ment data, and complete the post-processing of 3D data in one step.
High-Fidelity 3DGS Model Construction
Without relying on the SFM algorithm, it accurately recovers the pose of panoramic images in complex environments and generates high-quality Gaussian model data.
High-Precision Point Cloud Map Construction
Supporting the generation of indoor and outdoor colored point clouds with a relative accuracy of up to 2 cm.
High-Resolution Panoramic Image Stitching
Supporting the processing of original panoramic camera data, stitching high-resolution panoramic images with pose information, and achieving precise matching between panoramic images and point clouds.
Compatibility with Third-Party Modeling Software
It can output each frame of panoramic camera images and calibrated pose elements. It can also output standard Colmap-format data processed by the built-in SFM algorithm, compatible with mainstream or self-developed third-party modeling software such as MipMap and Postshot.
Result Browsing
Supporting the browsing and editing of point cloud data and 3DGS data results.
Note: Colored point clouds, panoramic images, and 3DGS models require an optional external camera.
Wide Range of Industry Applications