
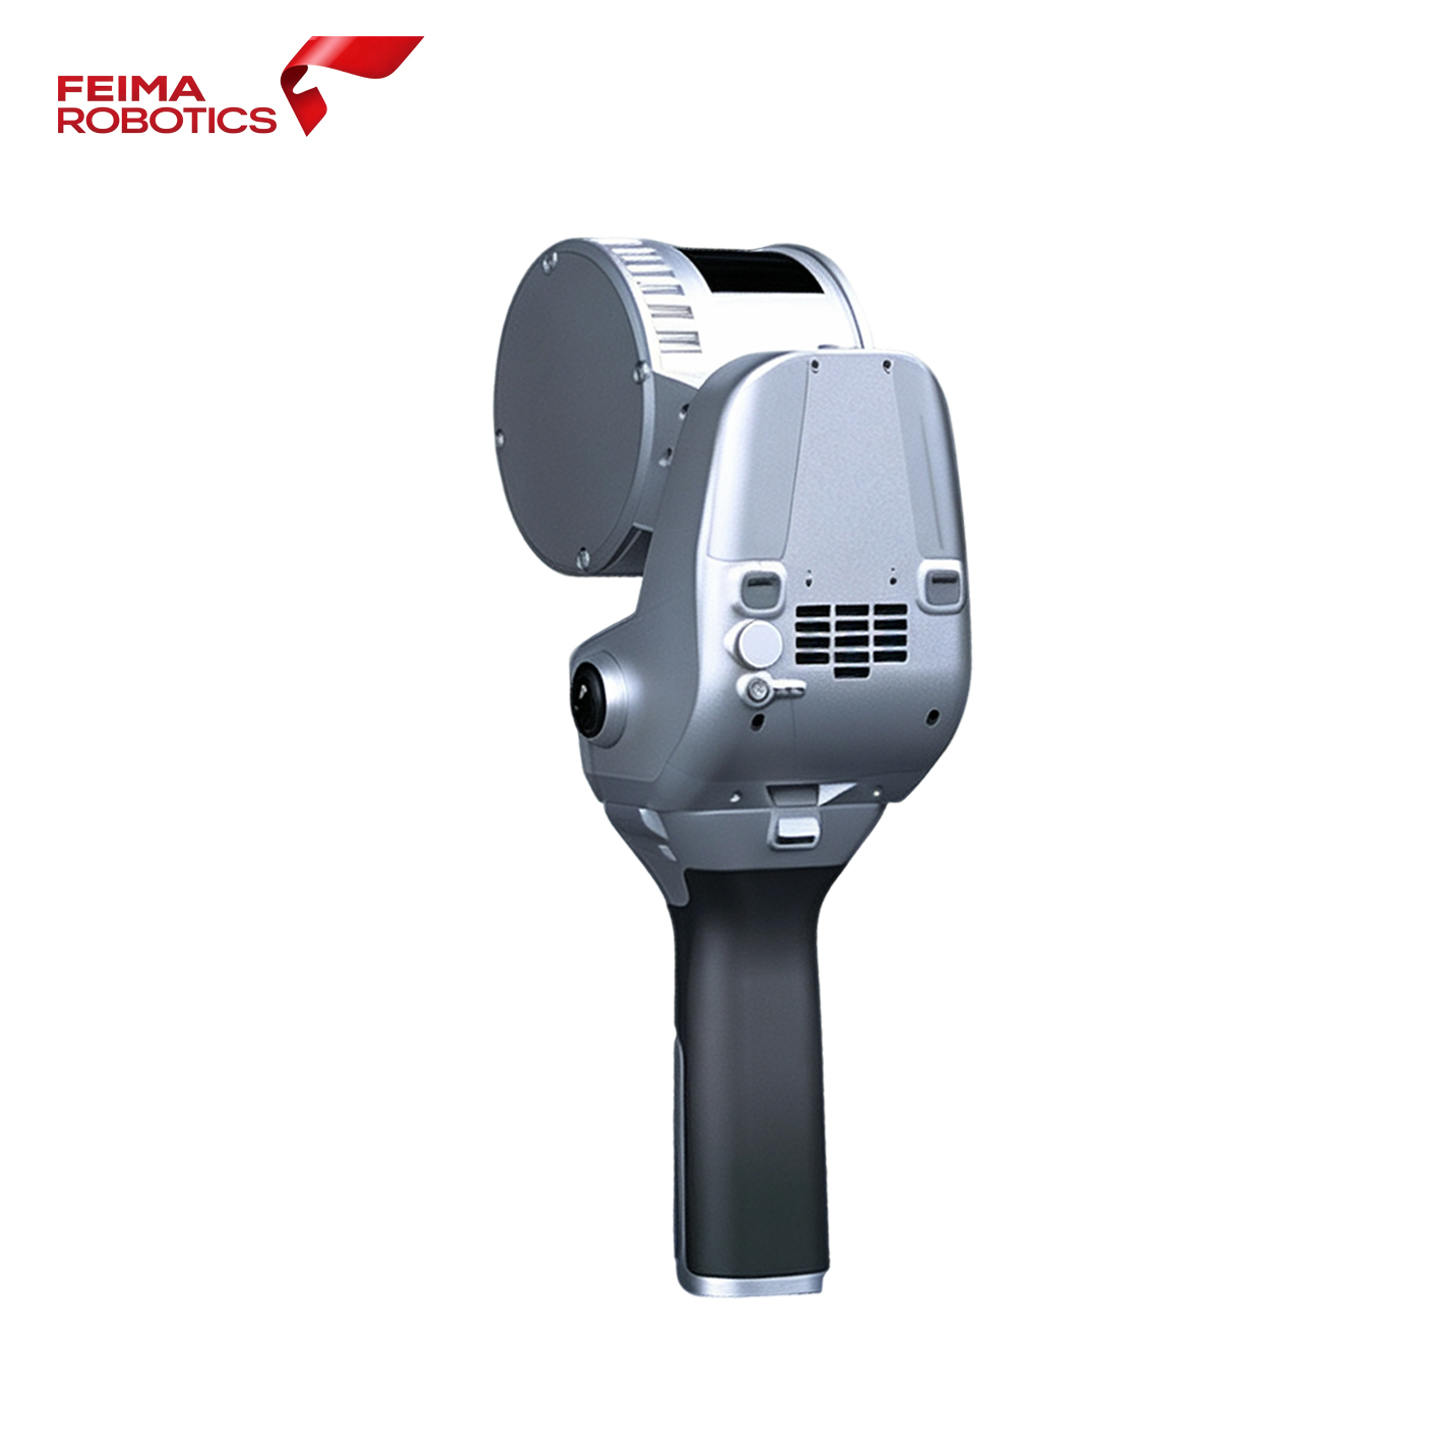
SLAM200E Industrial Handheld SLAM LiDAR Scanner | Feima Robotics
Core Advantages of SLAM200E
Ultra High Measuring Precision
5mm relative accuracy within 60m; up to 2cm absolute precision when paired with RTK or control points.
Stable SLAM Without GNSS
Reliable data acquisition inside tunnels, factories and underground parking without satellite signals.
Multi-working Mode Adaptable
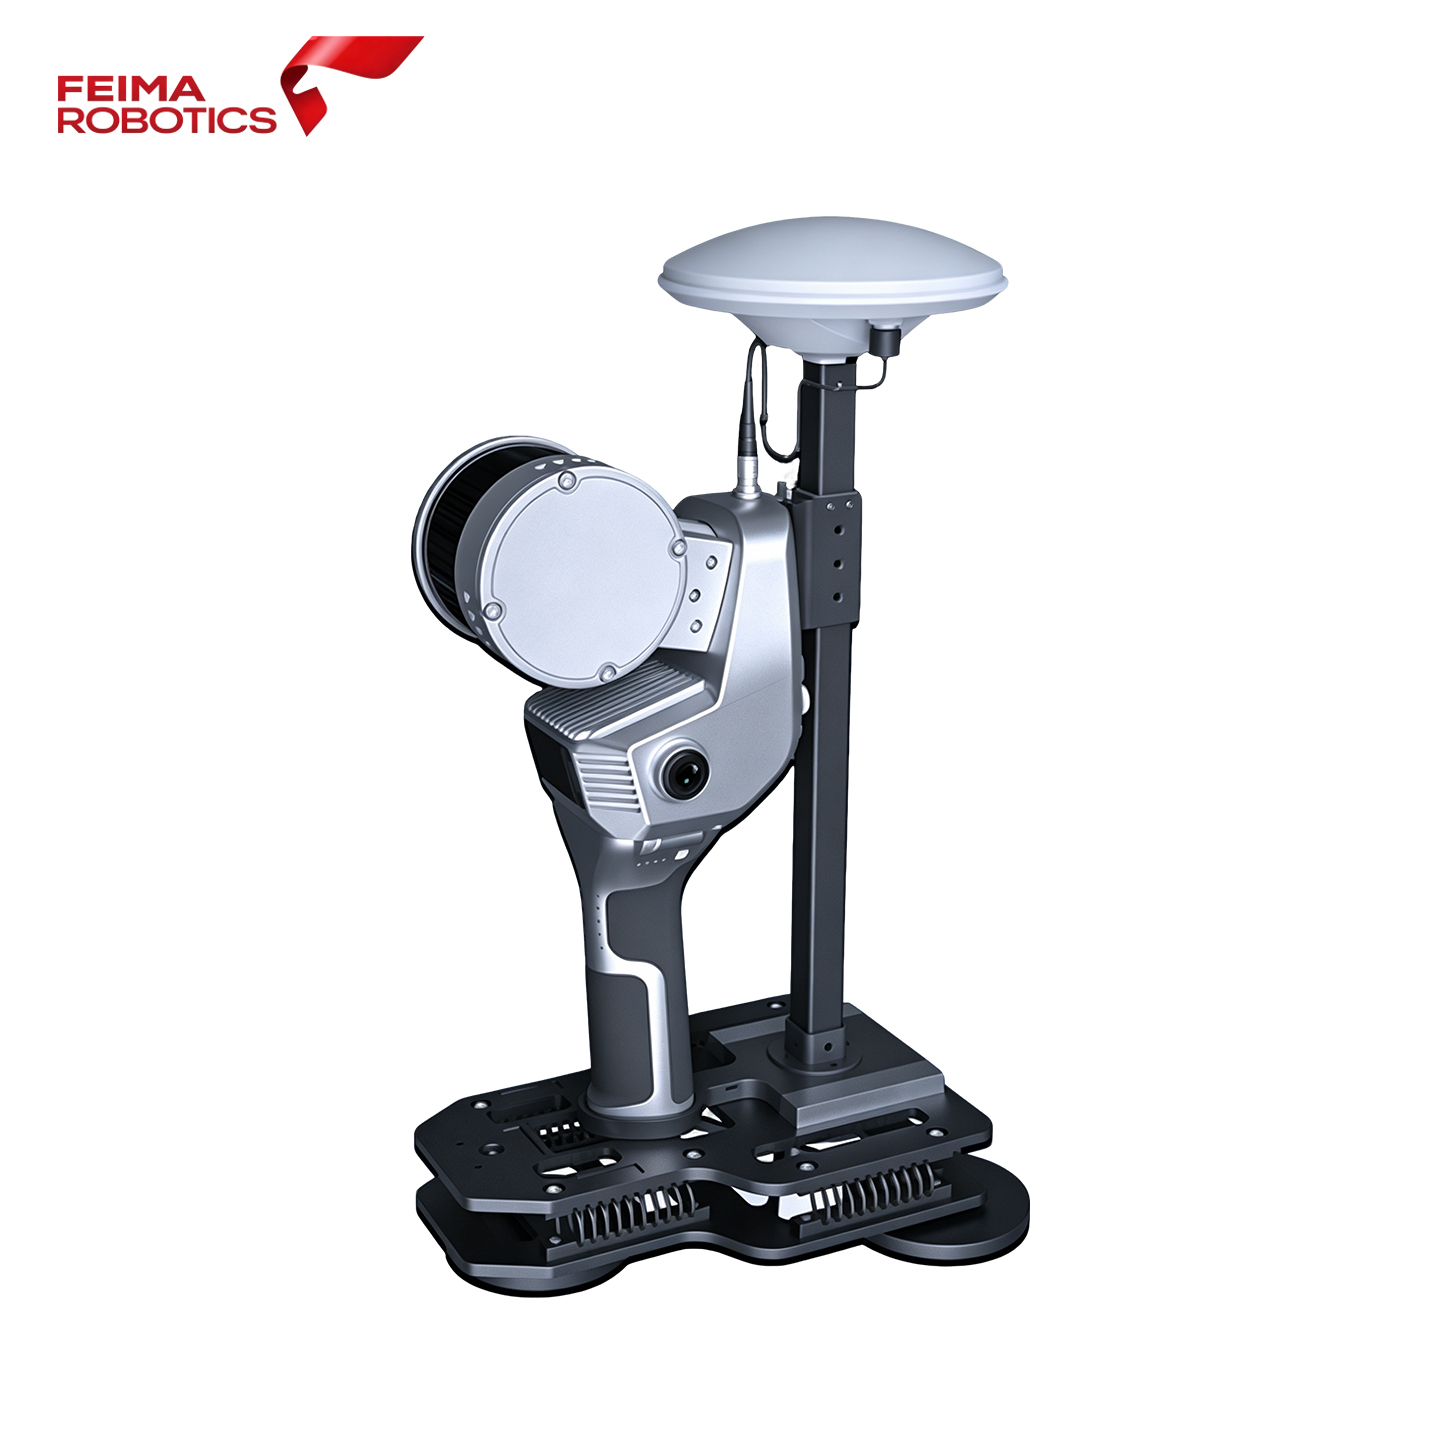
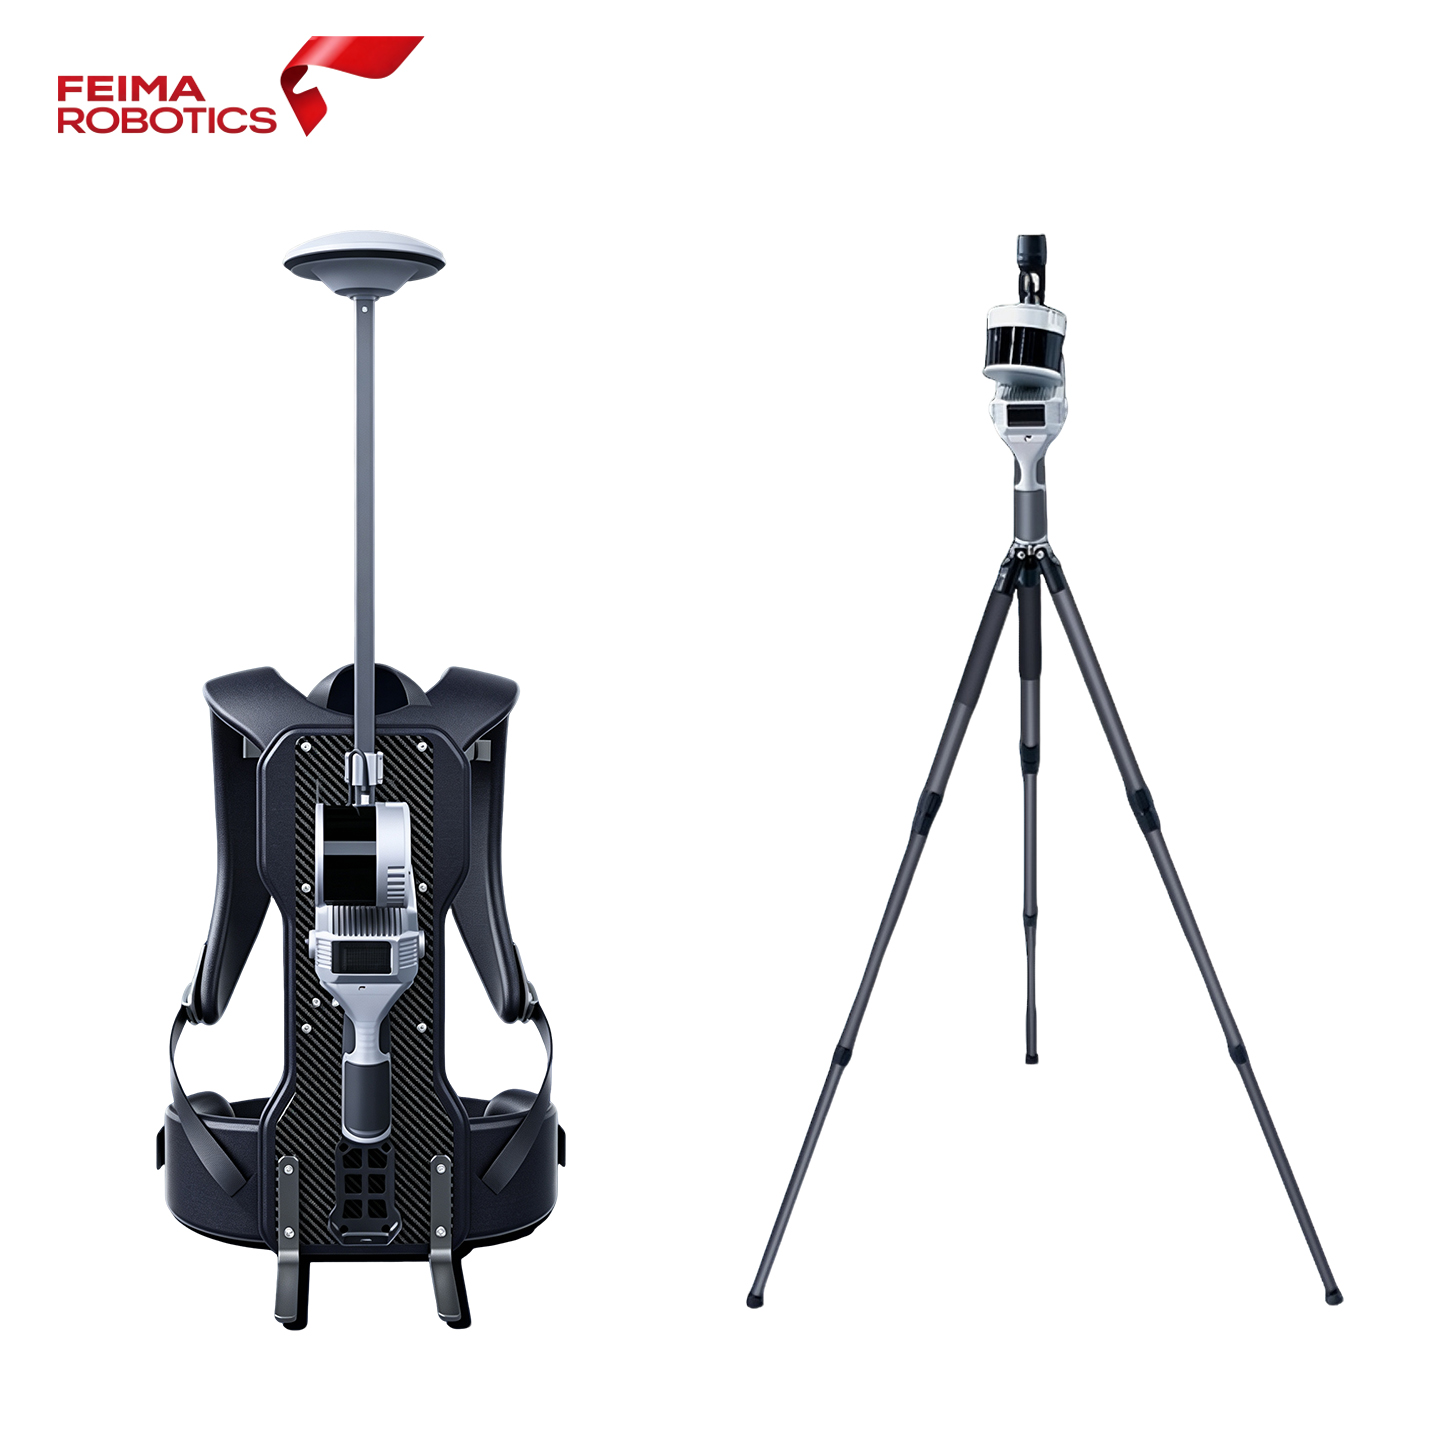
Support handheld, backpack, vehicle mount and UAV aerial mobile mapping solutions.
Dual 12MP Panoramic Cameras
Real-time colorized point cloud generation, native texture mapping for realistic 3D models.
Onboard Real-time Computing
Preview point cloud instantly on site, complete distance, area and volume instant measurement.
Rich Data Export Formats
Compatible with mainstream survey, BIM and 3D reconstruction software for seamless workflow.
Ultra High Precision Mobile Mapping
Built on upgraded SLAM algorithm, SLAM200E delivers stable and repeatable survey results for industrial and engineering projects.
- Relative Accuracy: 5 mm @ 60m scanning distance
- Relative Accuracy: 1 cm within 100 meters
- Absolute Accuracy: Up to 2 cm with RTK / Ground Control Points
- Supports closed-loop correction to reduce cumulative error
- Point frequency up to 640,000 points/sec for dense point cloud
-
PRODUCT DESCRIPTION
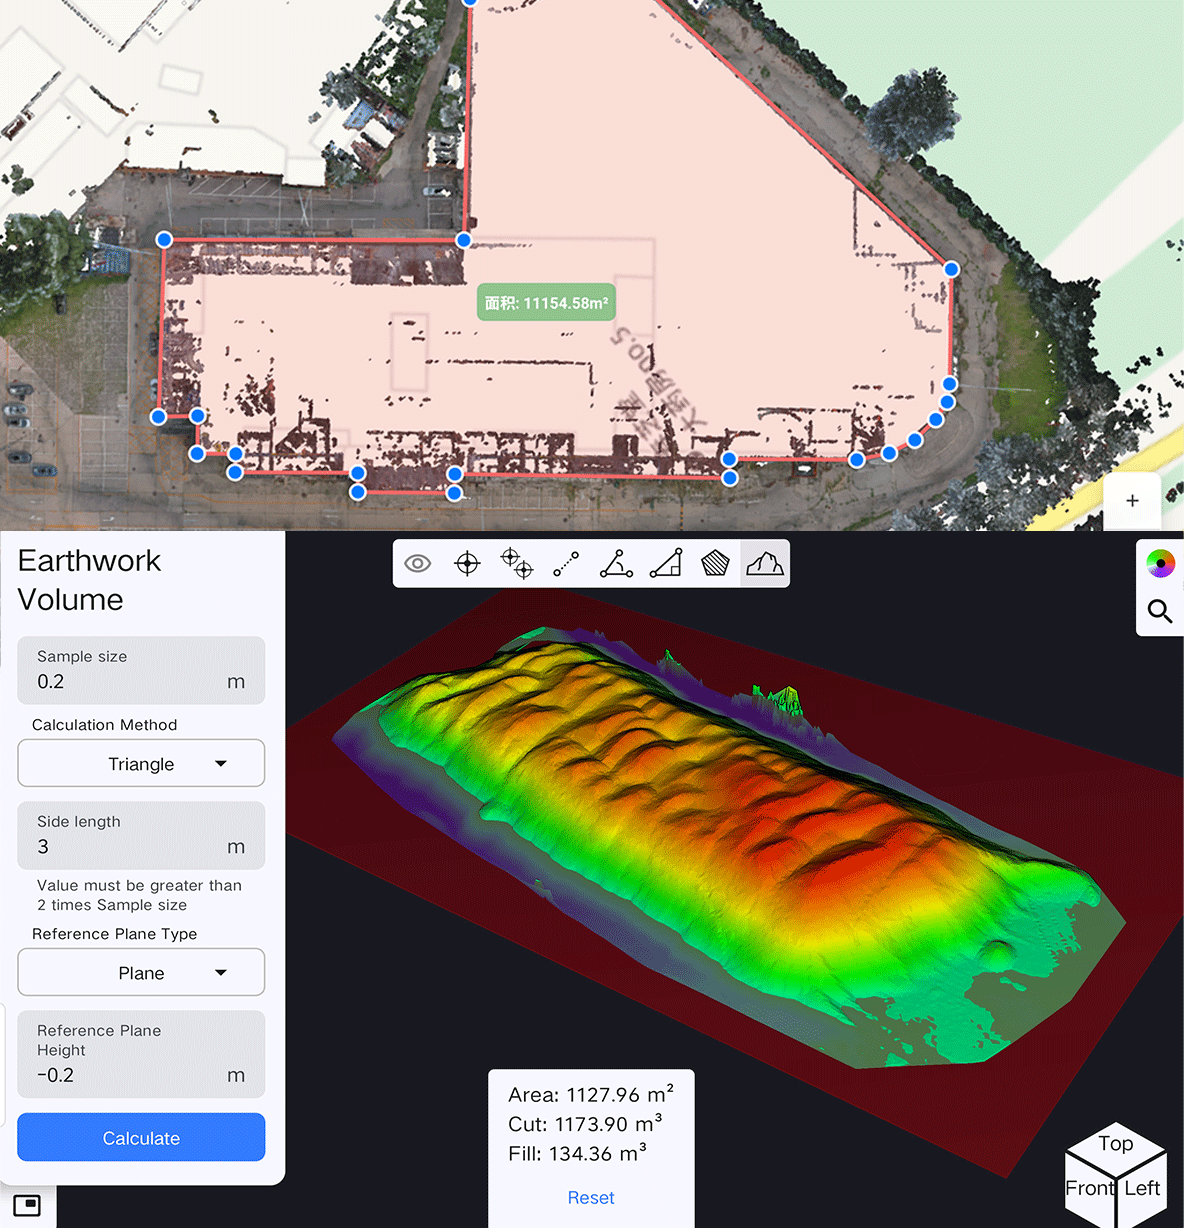
Instant Measurement
Normally, converting massive point cloud data requires professional software, skilled staff and extensive post-processing time. Paired with SLAM200E, SLAM Instant APP enables on-site instant measurement. Real-time point clouds captured in the field can be turned into industry-ready reports in minutes.
-
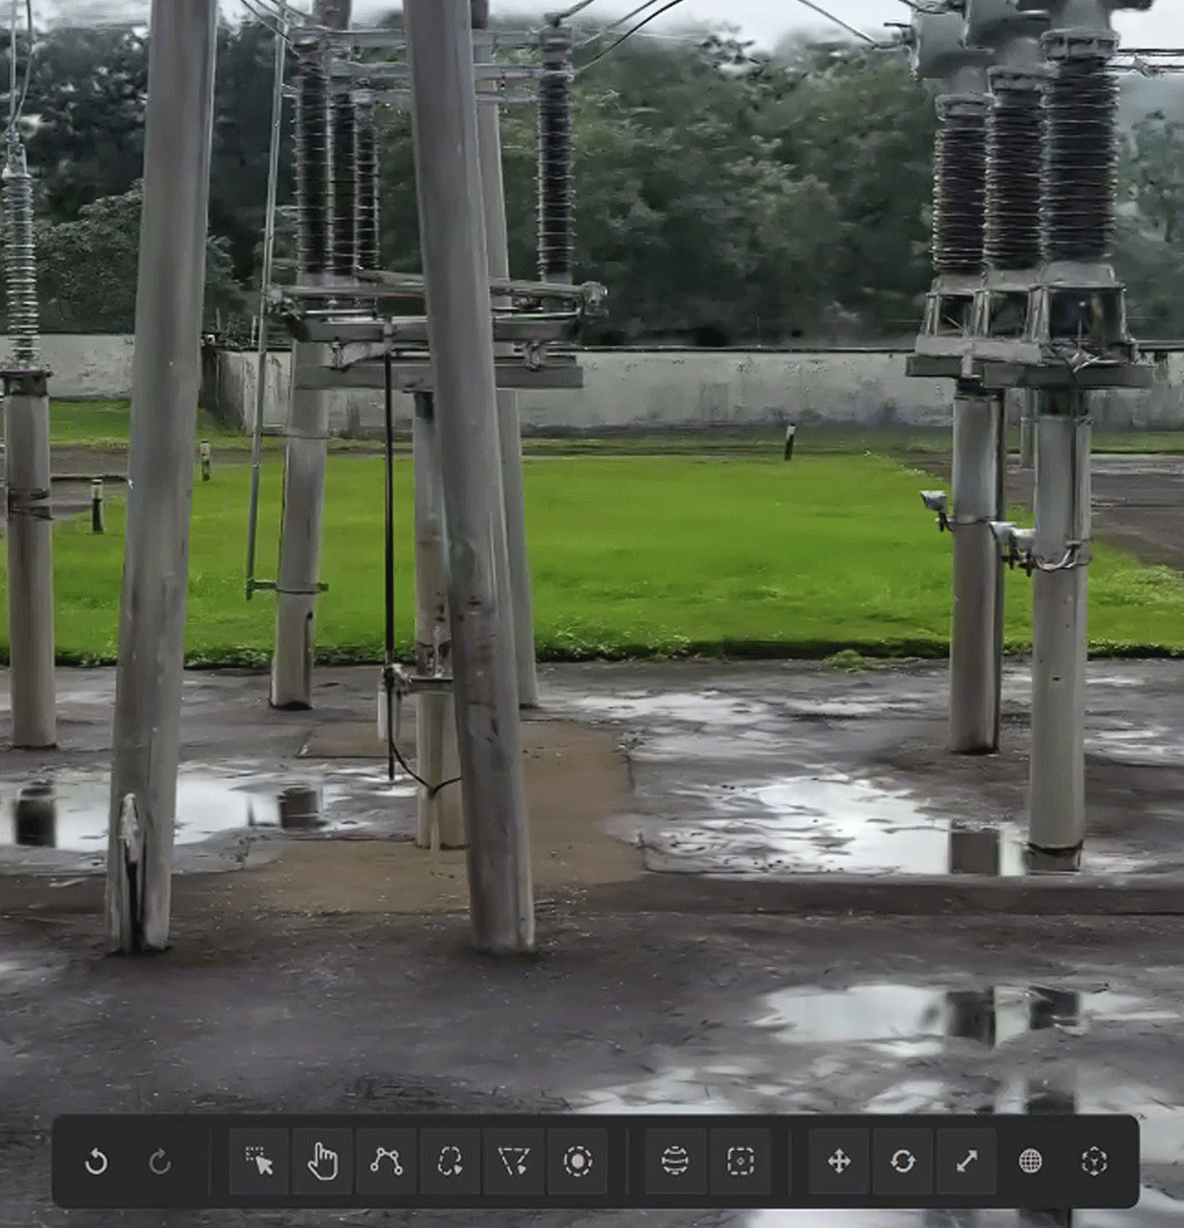
Gaussian Splatting(3DGS)
Powered by panoramic imagery, SLAM200E generates, views and applies large-scale Gaussian Splatting data. Universal formats enable easy compatibility with third-party platforms. Gaussian Splatting features are free forever for handheld LiDAR users.
-
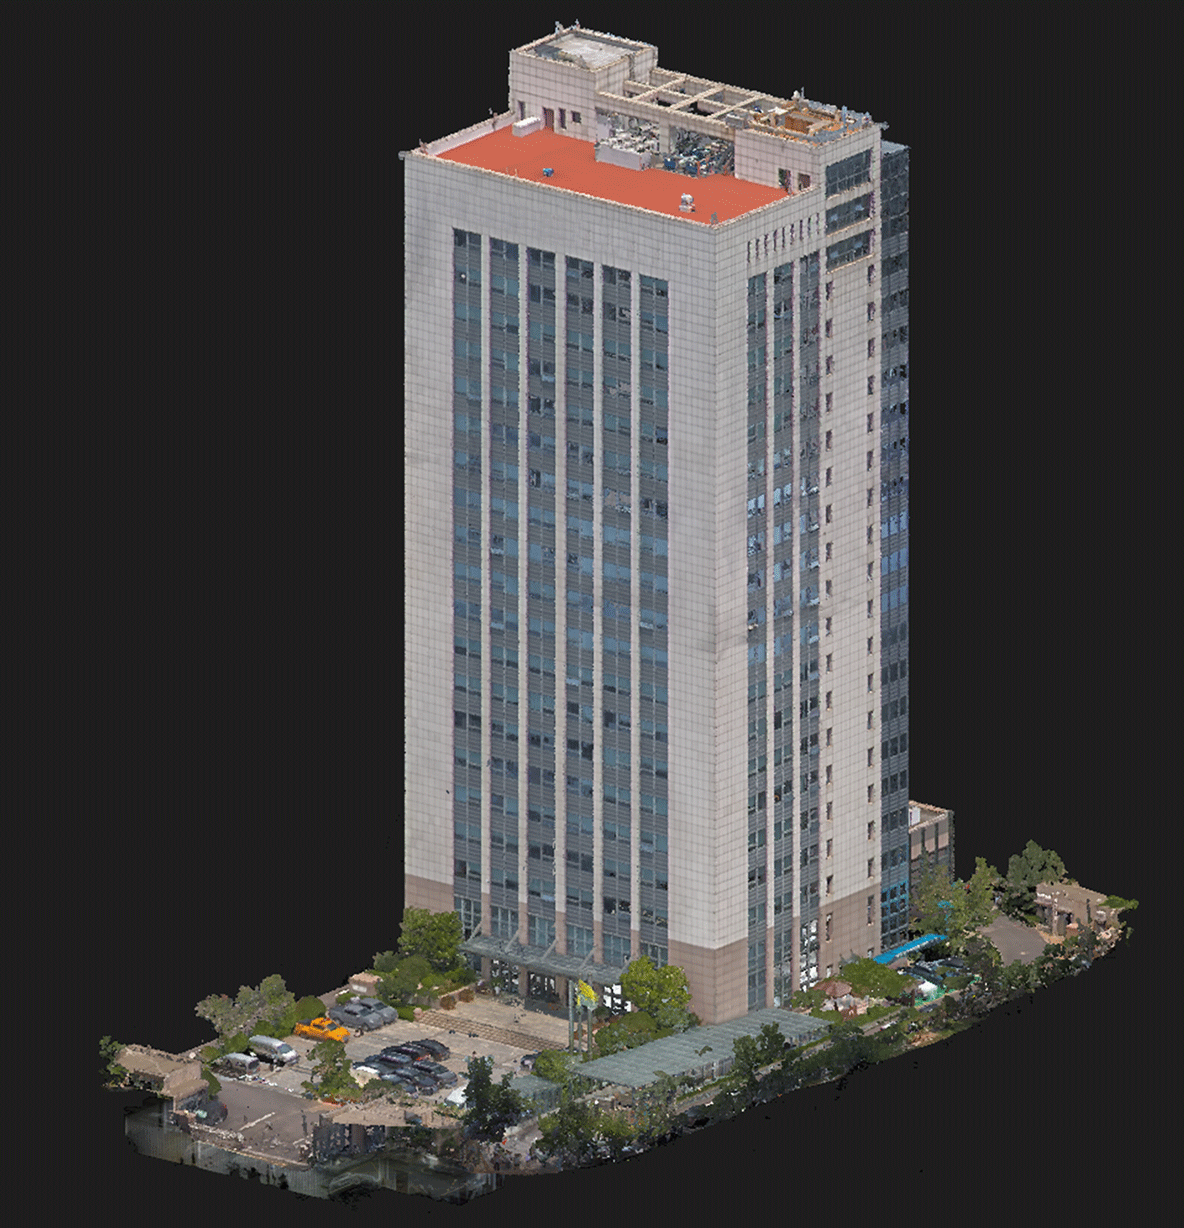
Air-Ground Data Fusion
Handheld laser scanners collect above-ground and underground 3D data, but some tasks require aerial point clouds. Feima Robotics’ air-ground fusion algorithms support airborne and handheld surveys, merging point clouds, images and 3D GIS for an all-in-one air-ground mapping solution.
-
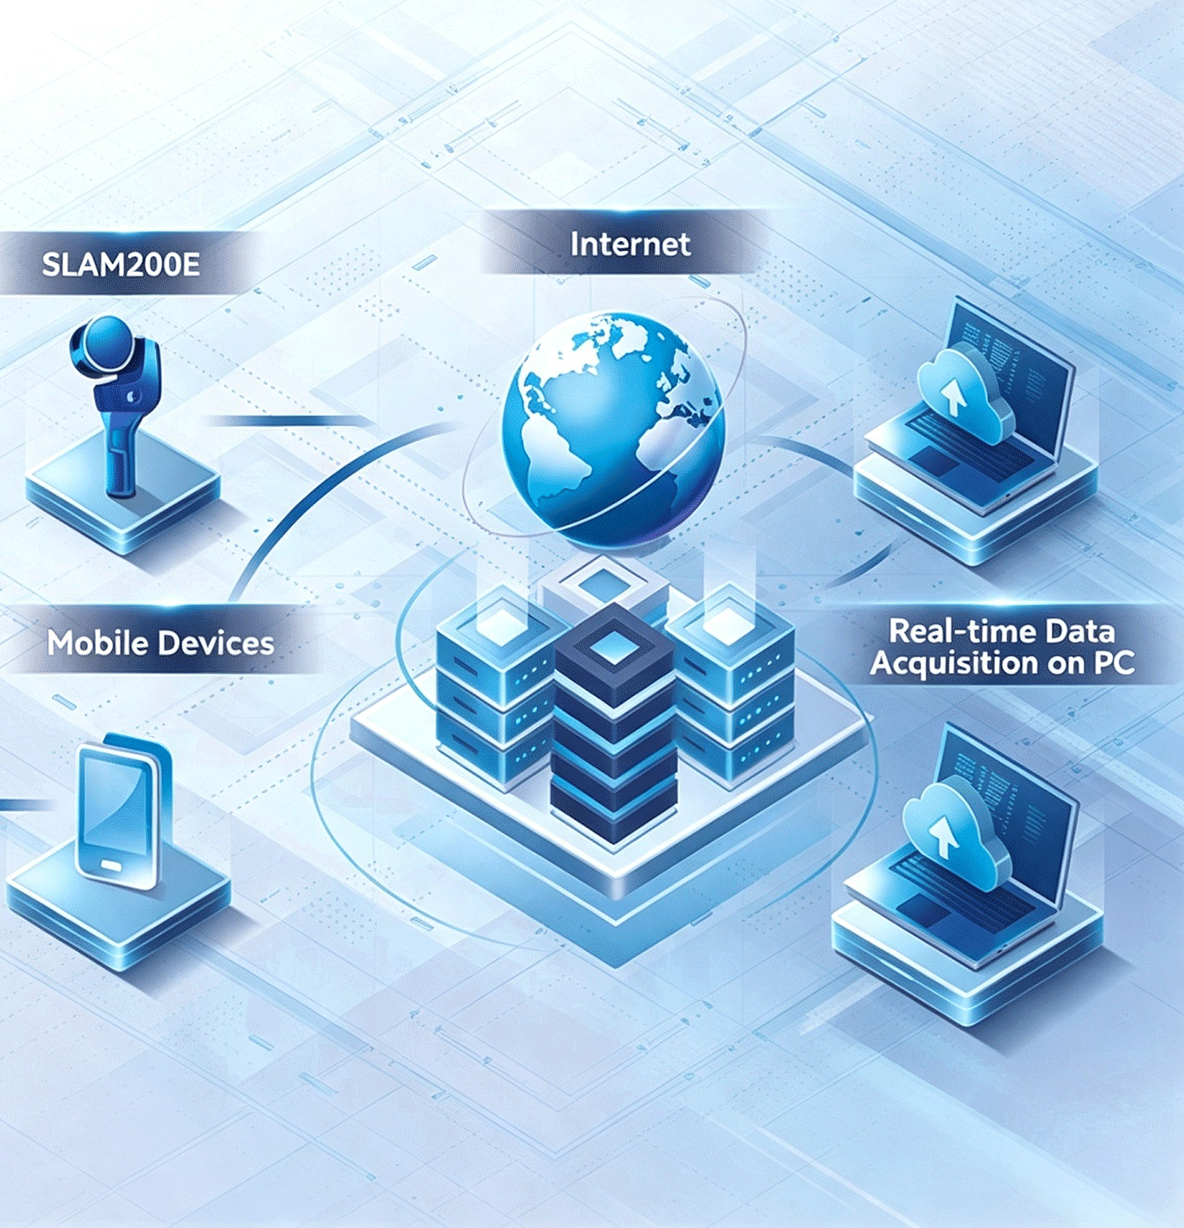
Remote Transmission
During real-time acquisition and mapping—especially in mining, emergency response, and similar scenarios—the handheld LiDAR scanner can stream mapping results in real time to a command center via LAN or the internet. This minimizes data aggregation time and accelerates decision-making.
Multiple Working Modes
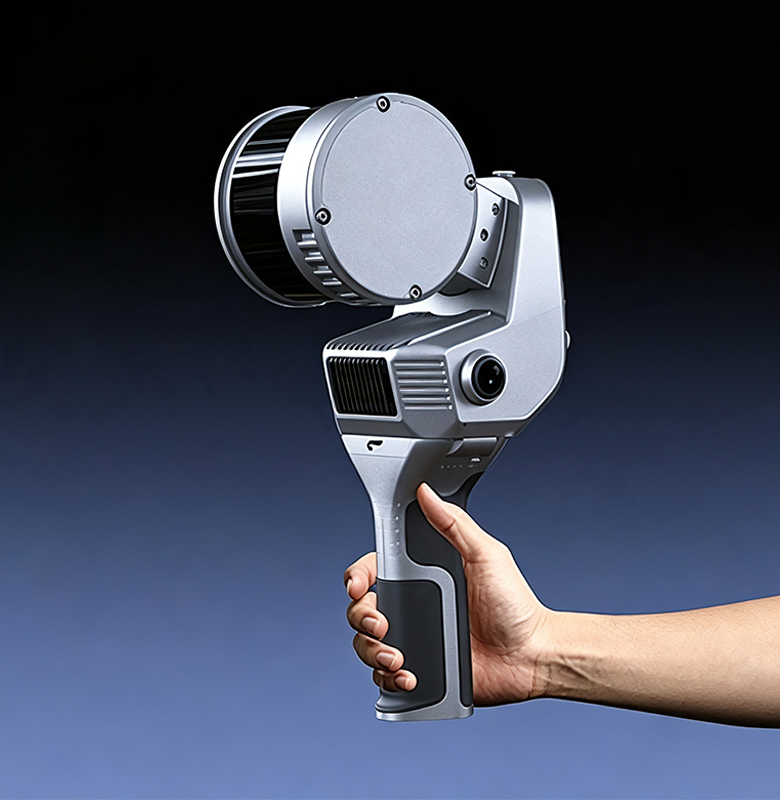
Handheld Mode
Flexible indoor inspection, building interior, underground space survey
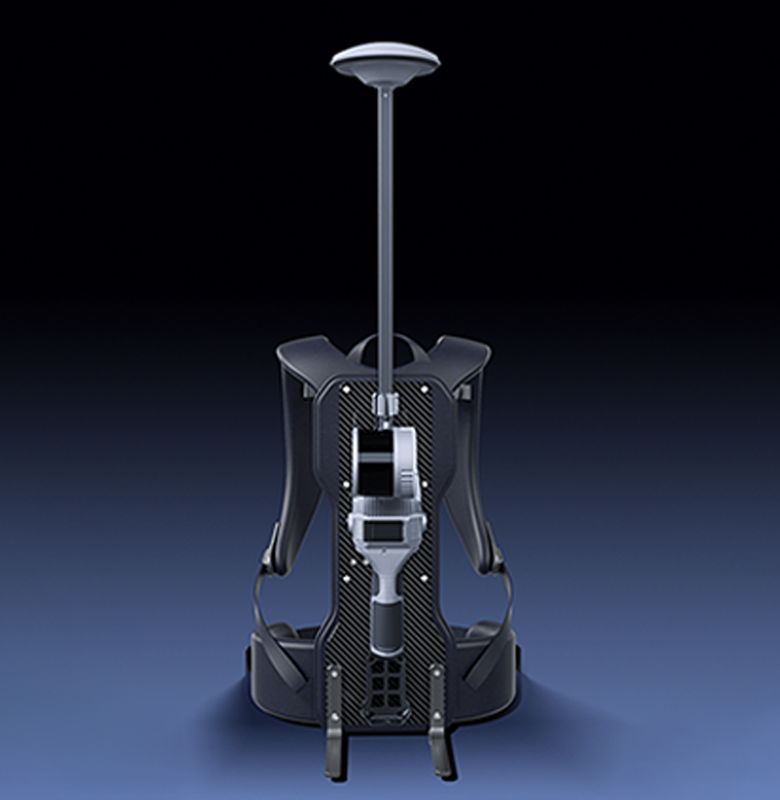
Backpack Mode
Large-area terrain, mine, forest and long-distance corridor mapping
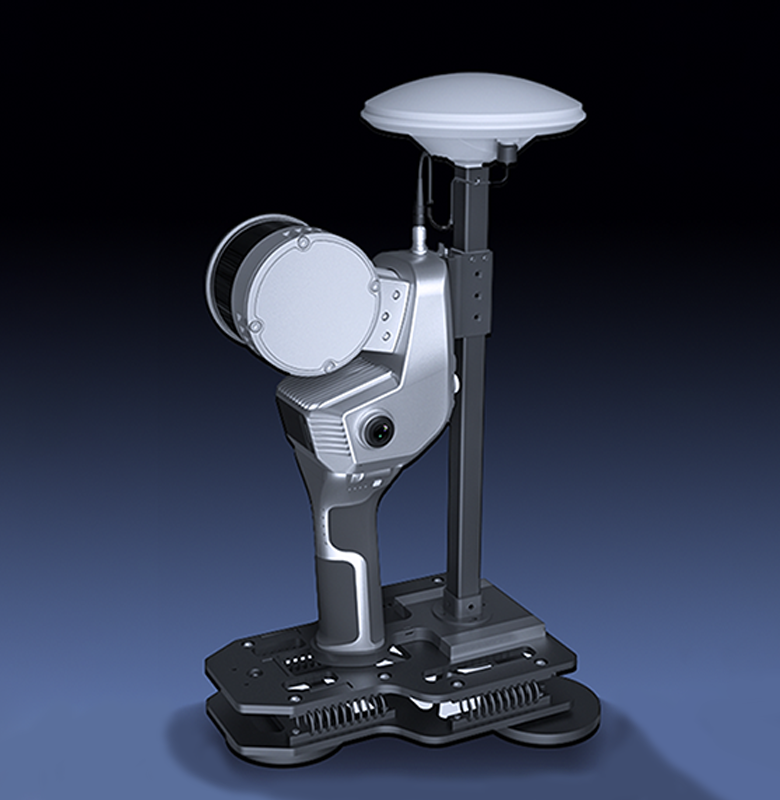
Vehicle Mount Mode
Road inventory, highway corridor, urban street rapid mapping
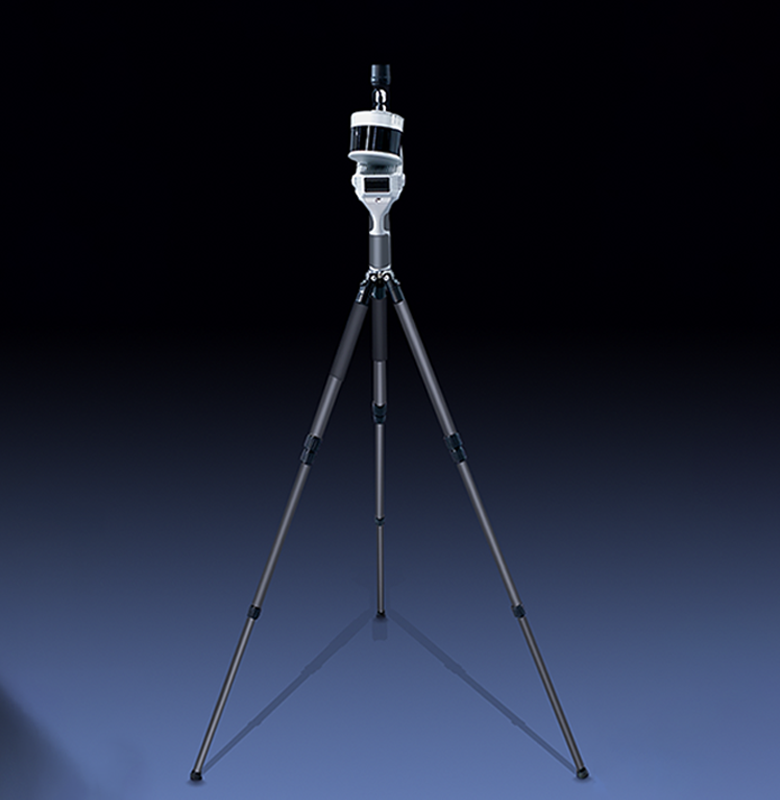
Static station mode
High-precision scanning for components, foundation pits and heritage details
Supporting Software
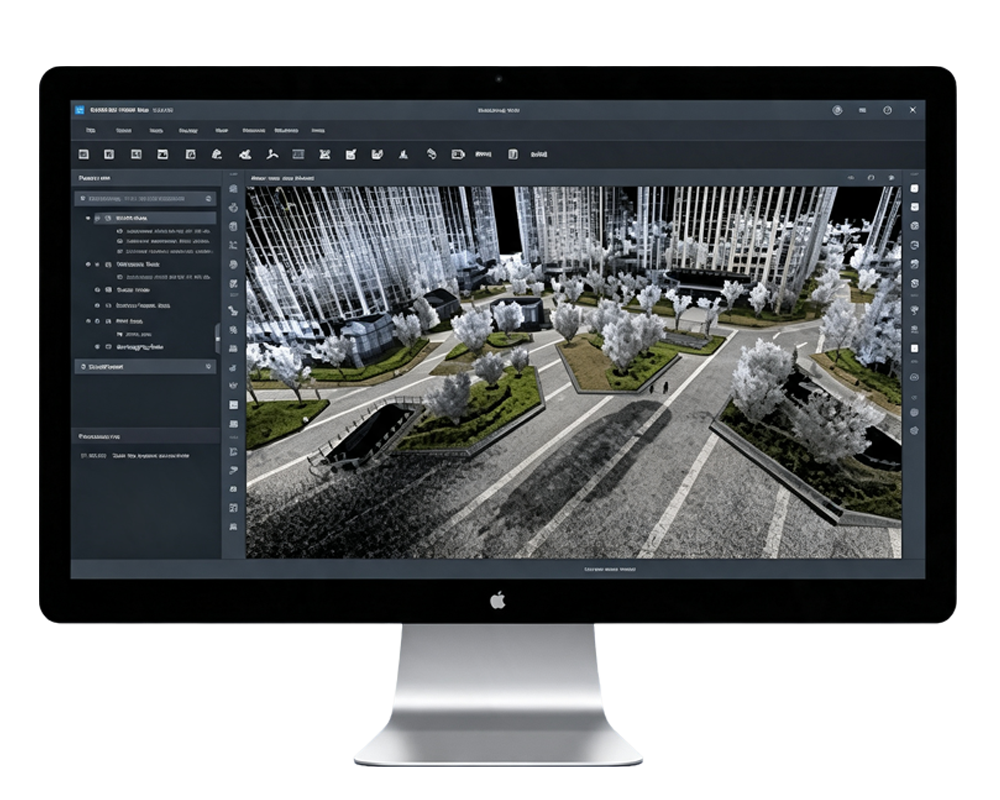
SLAM GO POST Pro is a professional PC-end data processing software specifically designed for Pocket3D. It is equipped with its own core data processing algorithm and supports the one-click generation ofpoint cloud, panoramic images, and Gaussian model results. It integrates a ful-process tool for resultbrowsing, visualization display, precise measurement, and interest point annotation. At the same time, itcan complete the unified management, batch processing, and fusion combination of multiple measure-ment data, and complete the post-processing of 3D data in one step.
High-Fidelity 3DGS Model Construction
Without relying on the SFM algorithm, it accurately recovers the pose of panoramic images in complex environments and generates high-quality Gaussian model data.
High-Precision Point Cloud Map Construction
Supporting the generation of indoor and outdoor colored point clouds with a relative accuracy of up to 2 cm.
High-Resolution Panoramic Image Stitching
Supporting the processing of original panoramic camera data, stitching high-resolution panoramic images with pose information, and achieving precise matching between panoramic images and point clouds.
Compatibility with Third-Party Modeling Software
It can output each frame of panoramic camera images and calibrated pose elements. It can also output standard Colmap-format data processed by the built-in SFM algorithm, compatible with mainstream or self-developed third-party modeling software such as MipMap and Postshot.
Result Browsing
Supporting the browsing and editing of point cloud data and 3DGS data results.
Note: Colored point clouds, panoramic images, and 3DGS models require an optional external camera.
Wide Range of Industry Applications
Main Body
|
Parameter |
Specification |
|---|---|
|
Weight |
1.6 kg (Scanner) / 2.1 kg (With battery and base) |
|
Size |
404 mm × 170 mm × 188 mm (With battery and base) |
|
Power Consumption |
26 W |
|
Storage |
512G SSD |
|
Lithium Battery |
SP30 |
|
Lithium Battery Endurance |
70 min (only SLAM200E) |
|
Operating Temperature |
-20°C ~ 50°C |
|
Humidity |
<95% |
|
Protection Class |
IP54 |
Laser
|
Parameter |
Specification |
|---|---|
|
Wavelength |
905 nm |
|
Laser Class |
Class 1 |
|
Range |
0.05 – 120 m |
|
FOV |
360°H, 270°V |
|
Point Frequency |
320 kpts/s (16 laser lines version) |
|
Point Frequency |
640 kpts/s (32 laser lines version) |
GNSS Module
|
Parameter |
Specification |
|---|---|
|
Satellite System |
GPS | GLONASS | GALILEO | BDS | QZSS |
|
Positioning Accuracy (RTK) |
Horizontal: 0.8 cm + 1 ppm; Vertical: 1.5 cm + 1 ppm |
High-Precision IMU
|
Parameter |
Specification |
|---|---|
|
Bias Instability |
0.5°/h (Allan Variance @25℃) |
|
Angle Random Walk (ARW) |
0.025°/√hr |
Interface
|
Parameter |
Specification |
|---|---|
|
Type-C1 |
Charge | OTG | 20V external power |
|
Type-C2 |
SSD |
|
Wi-Fi |
Supported |
|
Bluetooth |
Supported |
Real-Time Result Accuracy
|
Parameter |
Specification |
|---|---|
|
Absolute Accuracy (RMSE) |
3 cm |
|
Relative Accuracy (RMSE) |
2 cm @ 100 m |
|
Point Cloud Thickness (Noise) |
2 cm |
Post-Processing Result Accuracy
|
Parameter |
Specification |
|---|---|
|
Absolute Accuracy (RMSE) |
3 cm |
|
Relative Accuracy (RMSE) |
Handheld Mode: 1 cm @ 100 m; Control Point-Assisted Mode[1]: 5 mm @ 60 m |
|
Repeat Accuracy (RMSE) |
2 cm (Two uninterrupted RTK scans) |
|
Point Cloud Thickness (Noise) |
0.5 cm (Point cloud planar thickness within 50 m of the odometry center) |
[1] Relative accuracy: Typical test environment within 100 m × 100 m. In RTK mode, the relative accuracy depends on the quality of RTK data and the field environment.